Workshop Posters
Explore the papers and posters accepted at the Sim2Real and Classical Control Workshop at IROS 2026.
Click on a poster to view the full-resolution version or download the PDF.
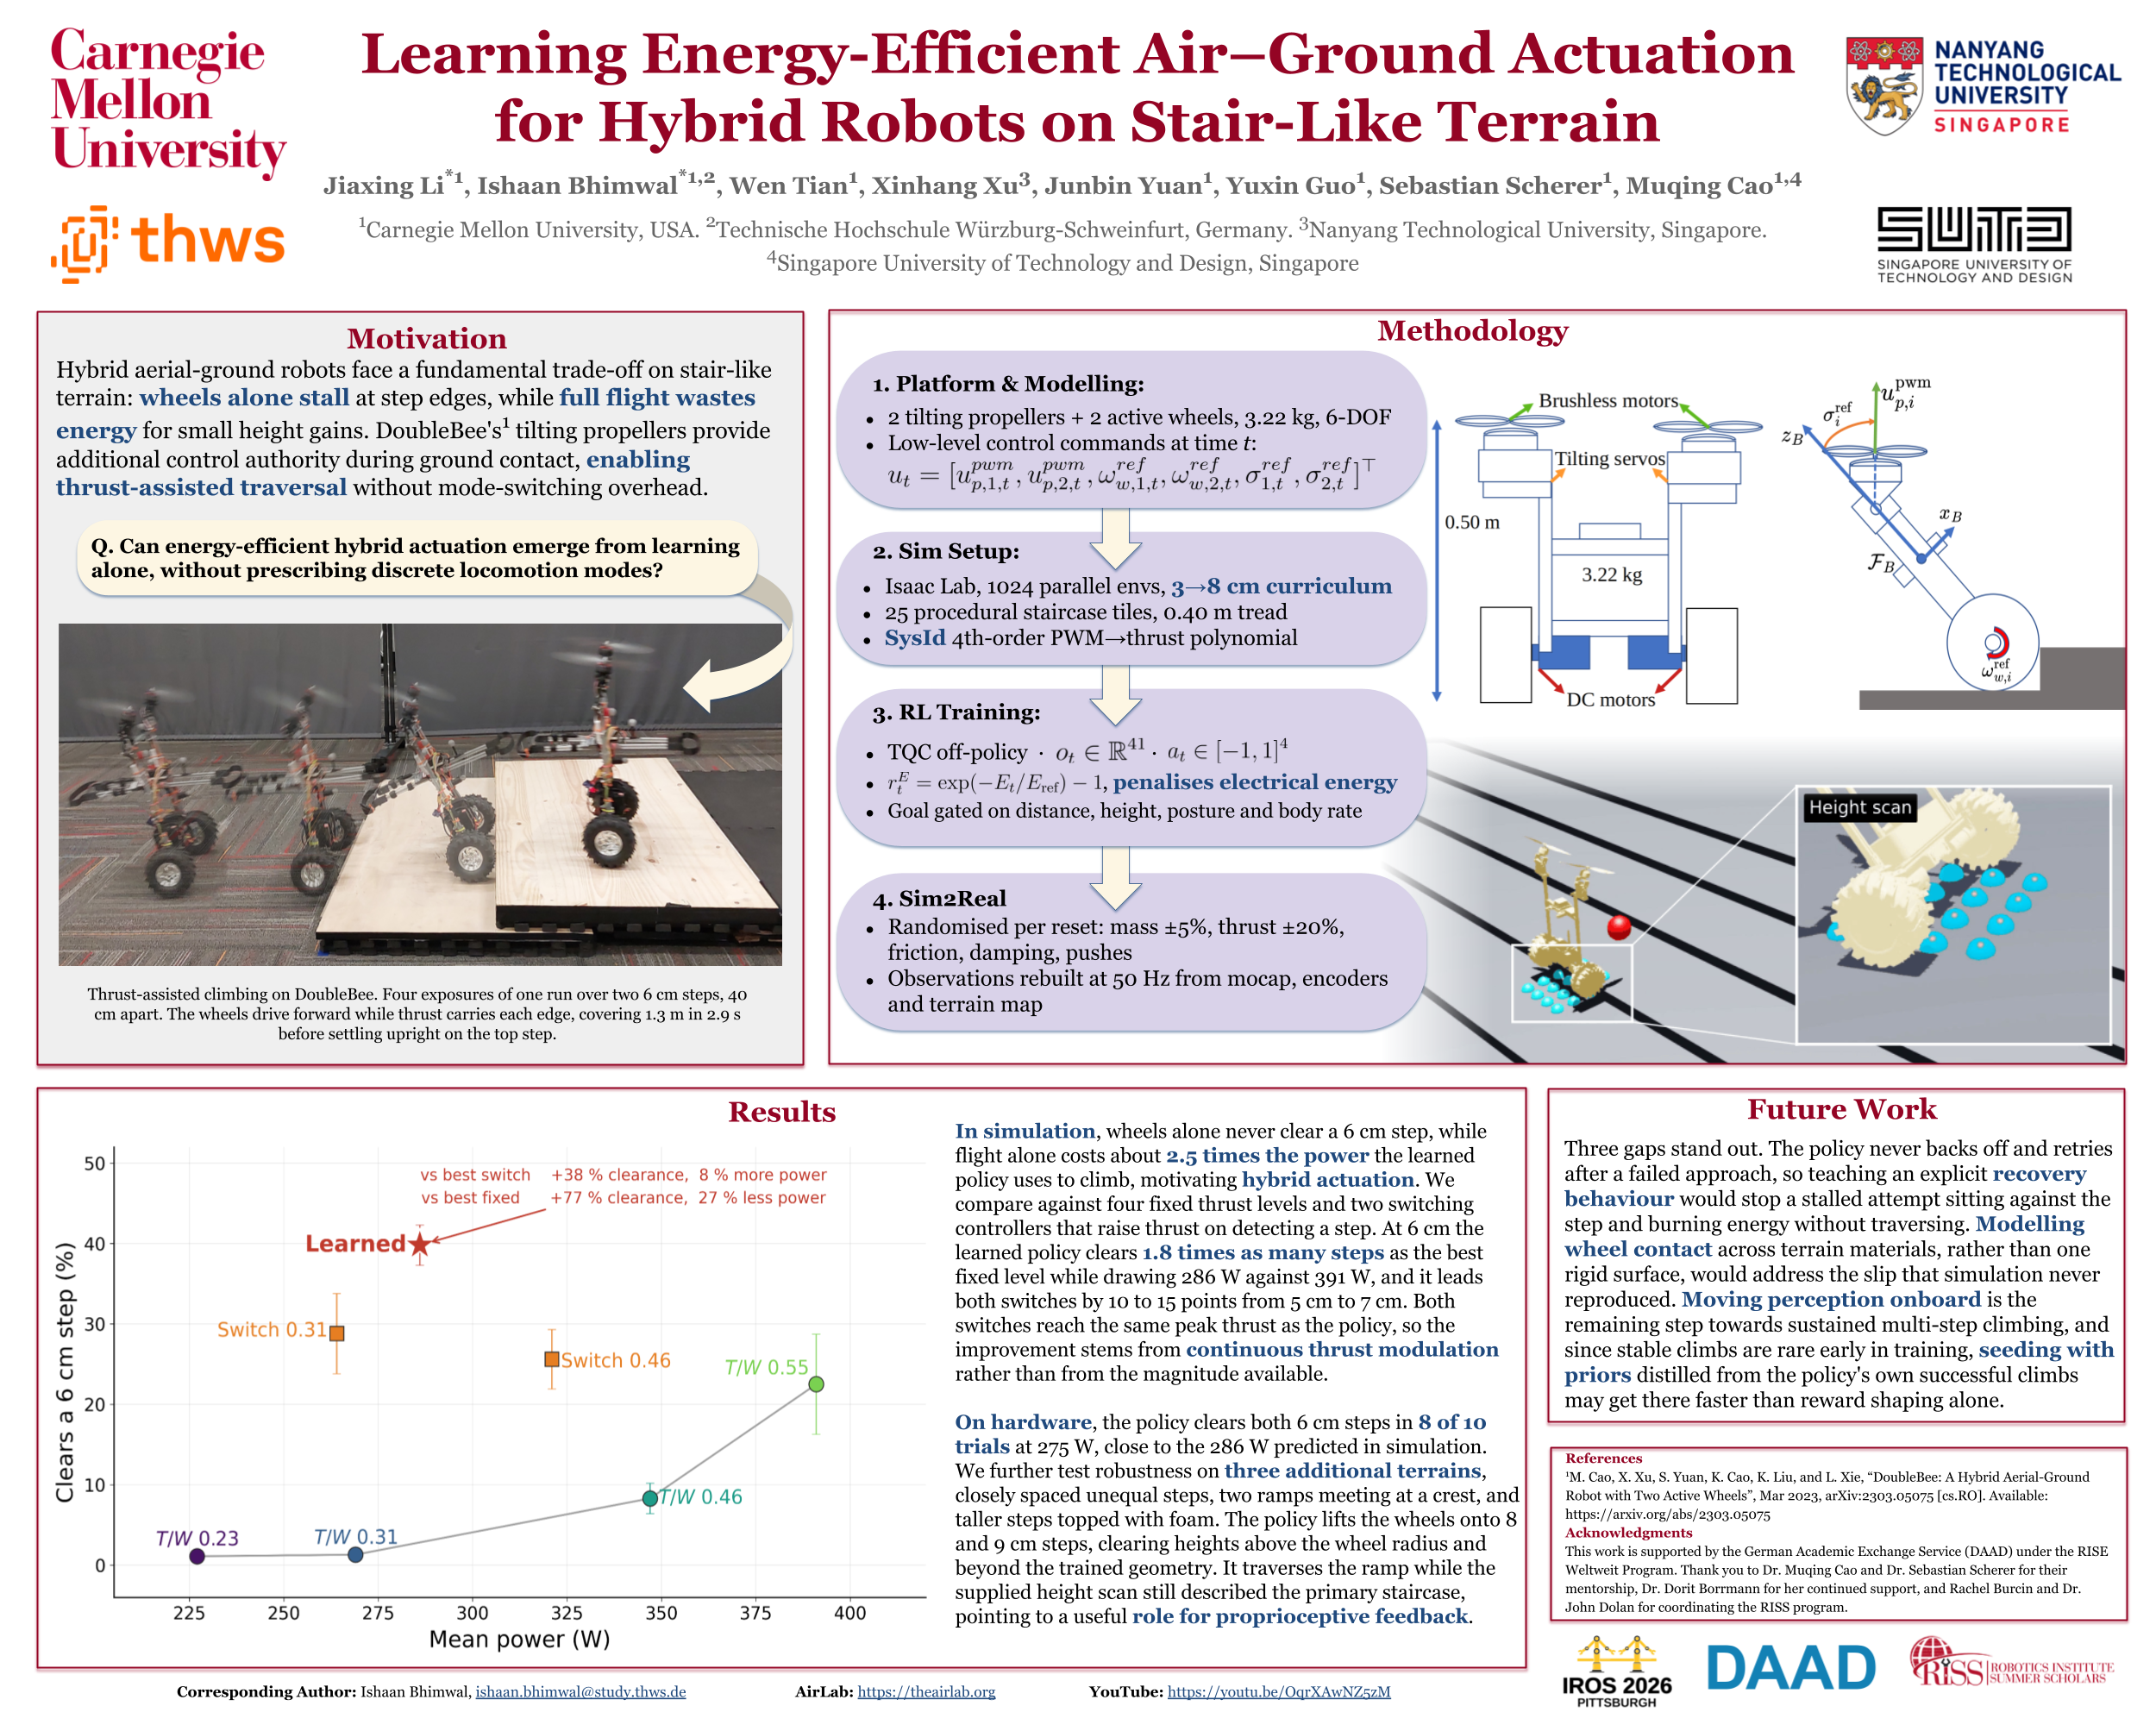
Learning Energy-Efficient Air-Ground Actuation for Hybrid Robots on Stair-Like Terrain
Wen Tian, Xinhang Xu, Sebastian Scherer, Muqing Cao, Junbin Yuan, Jiaxing Li, Ishaan Bhimwal
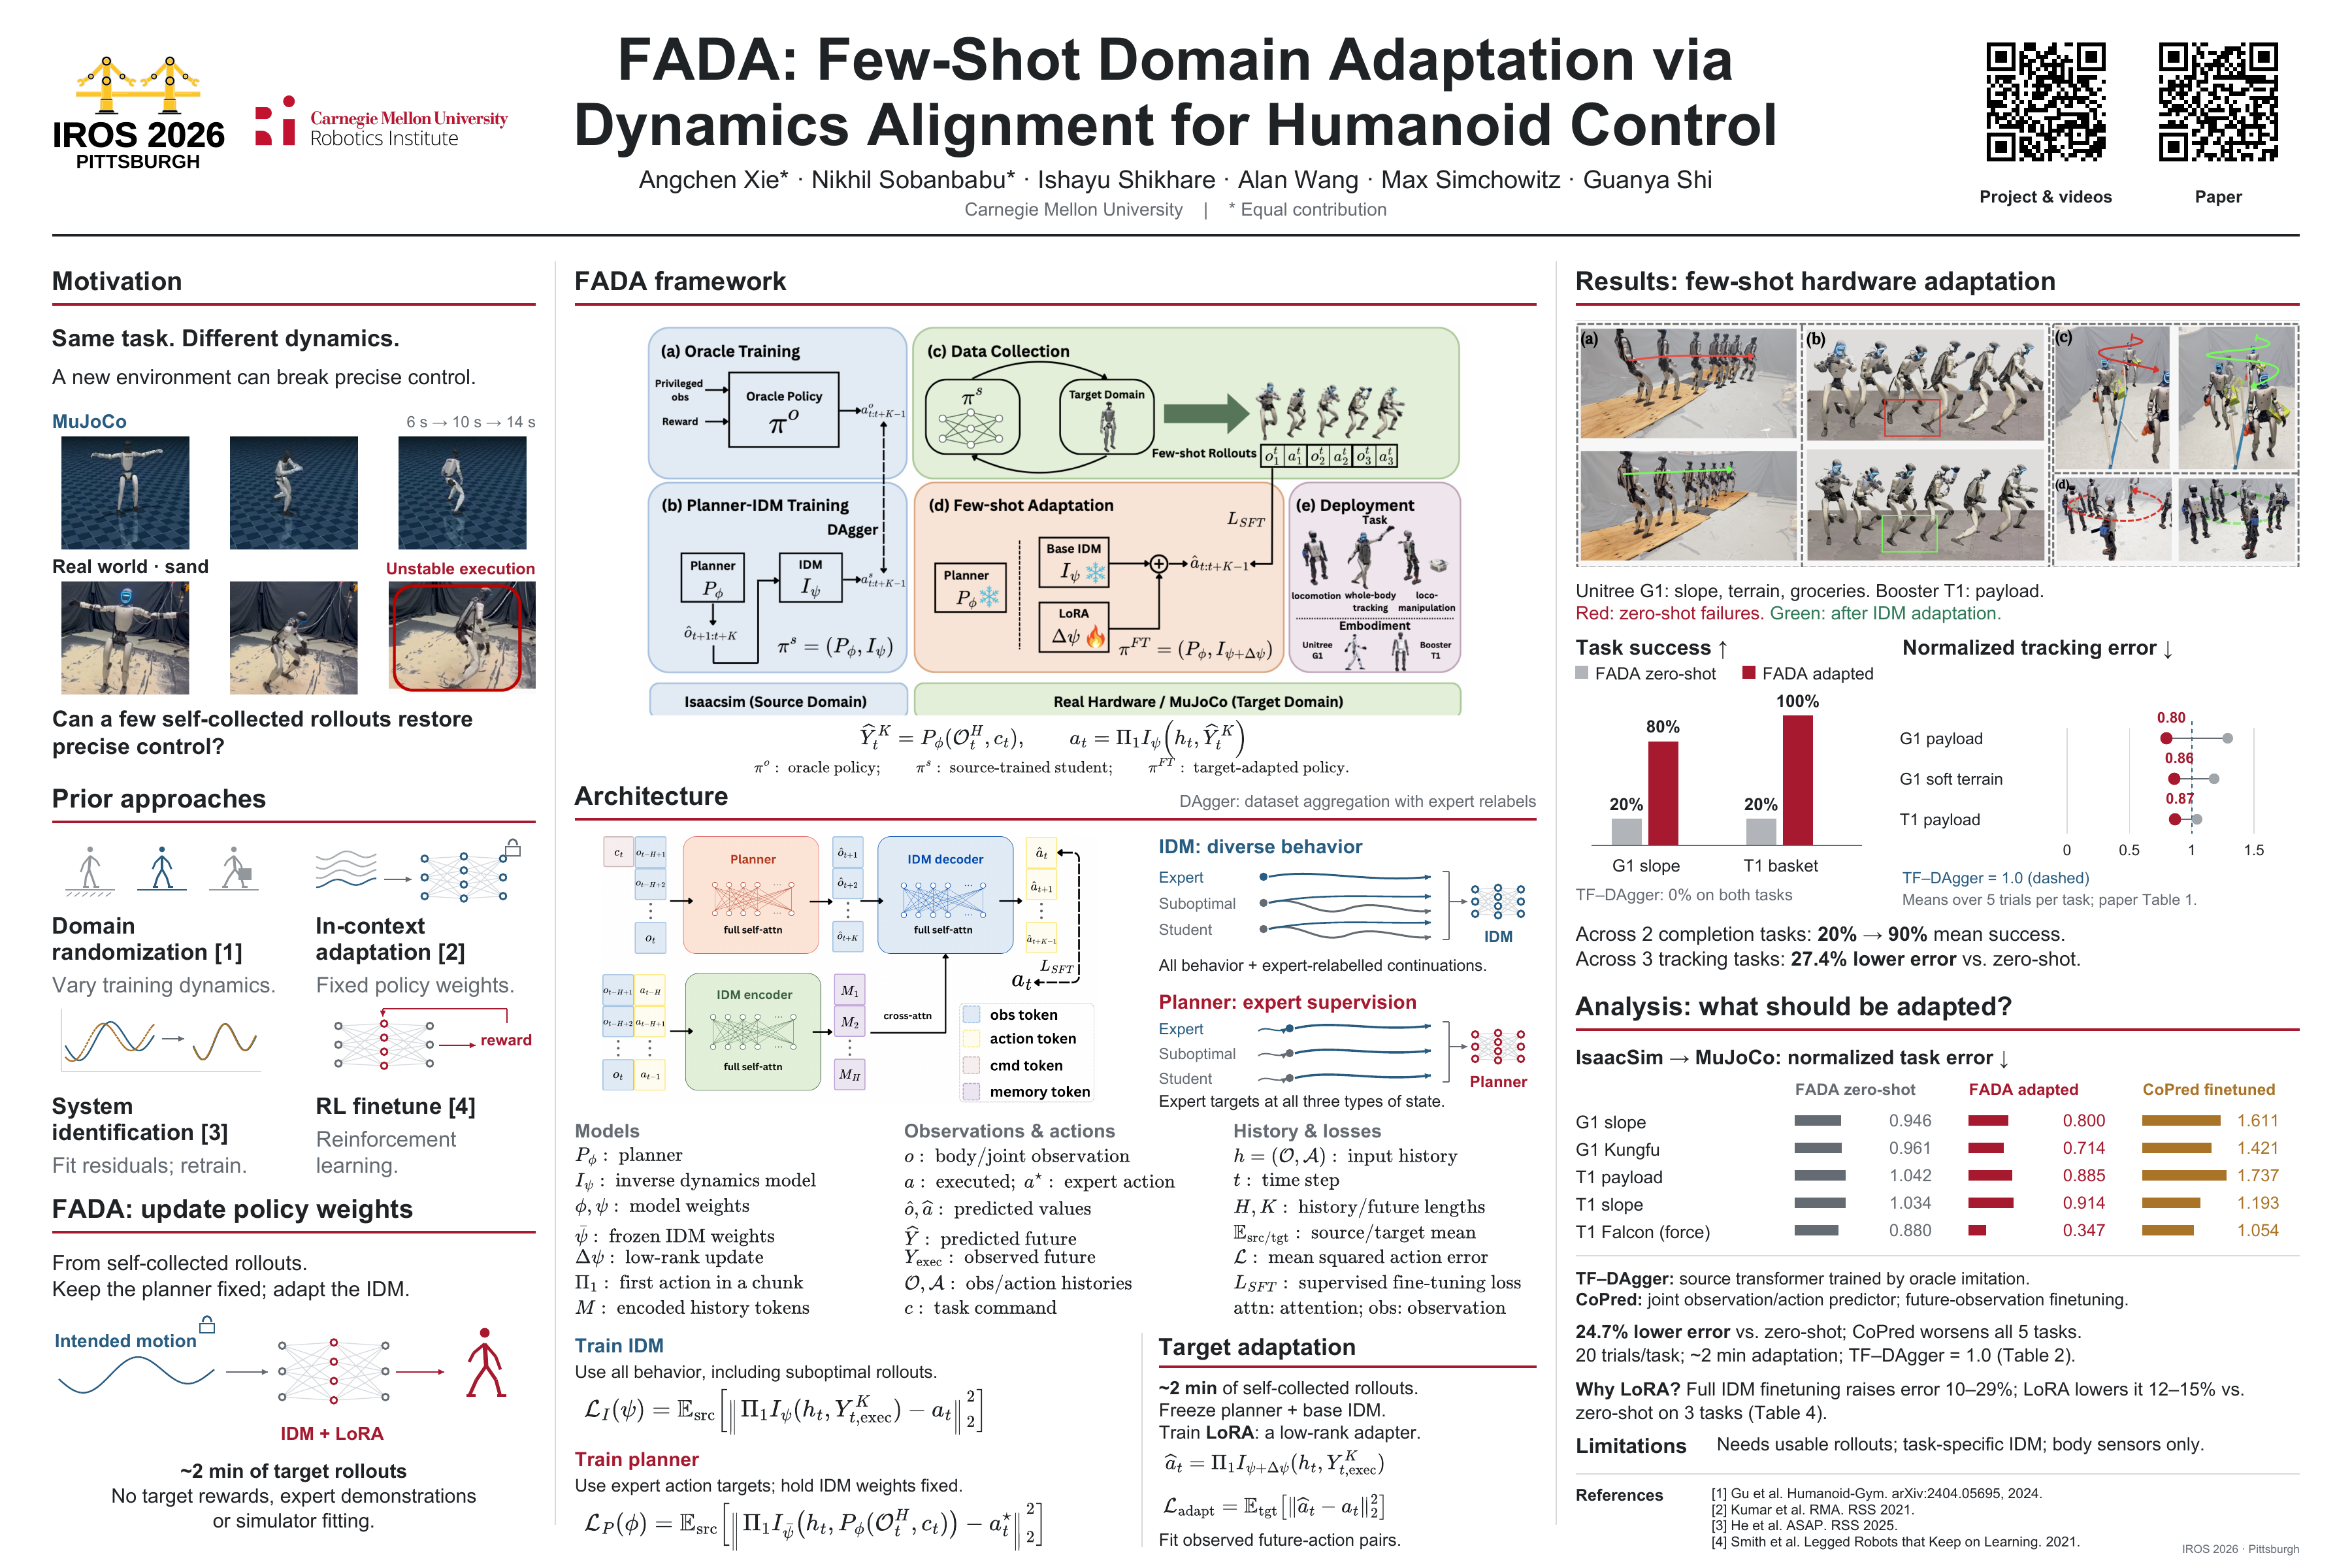
FADA: Few-Shot Domain Adaptation via Dynamics Alignment for Humanoid Control
Nikhil Sobanbabu, Max Simchowitz, Ishayu Shikhare, Guanya Shi, Angchen Xie, Alan Wang
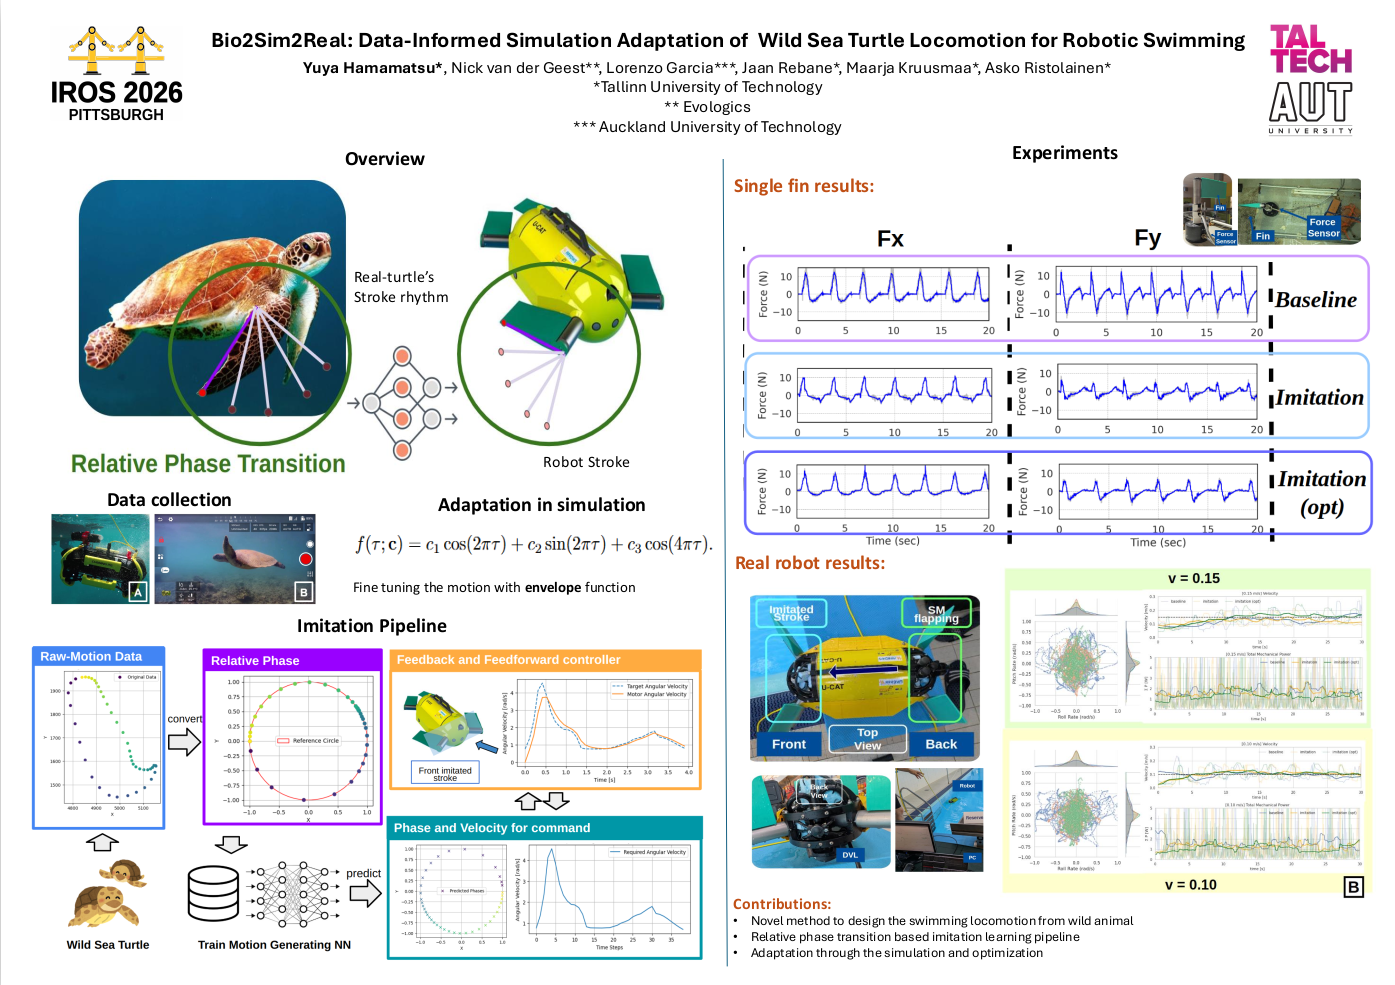
Bio2Sim2Real: Data-Informed Simulation Adaptation of Wild Sea Turtle Locomotion for Robotic Swimming
Yuya Hamamatsu, Nick van der Geest, Maarja Kruusmaa, Lorenzo Garcia, Jaan Rebane, Asko Ristolainen
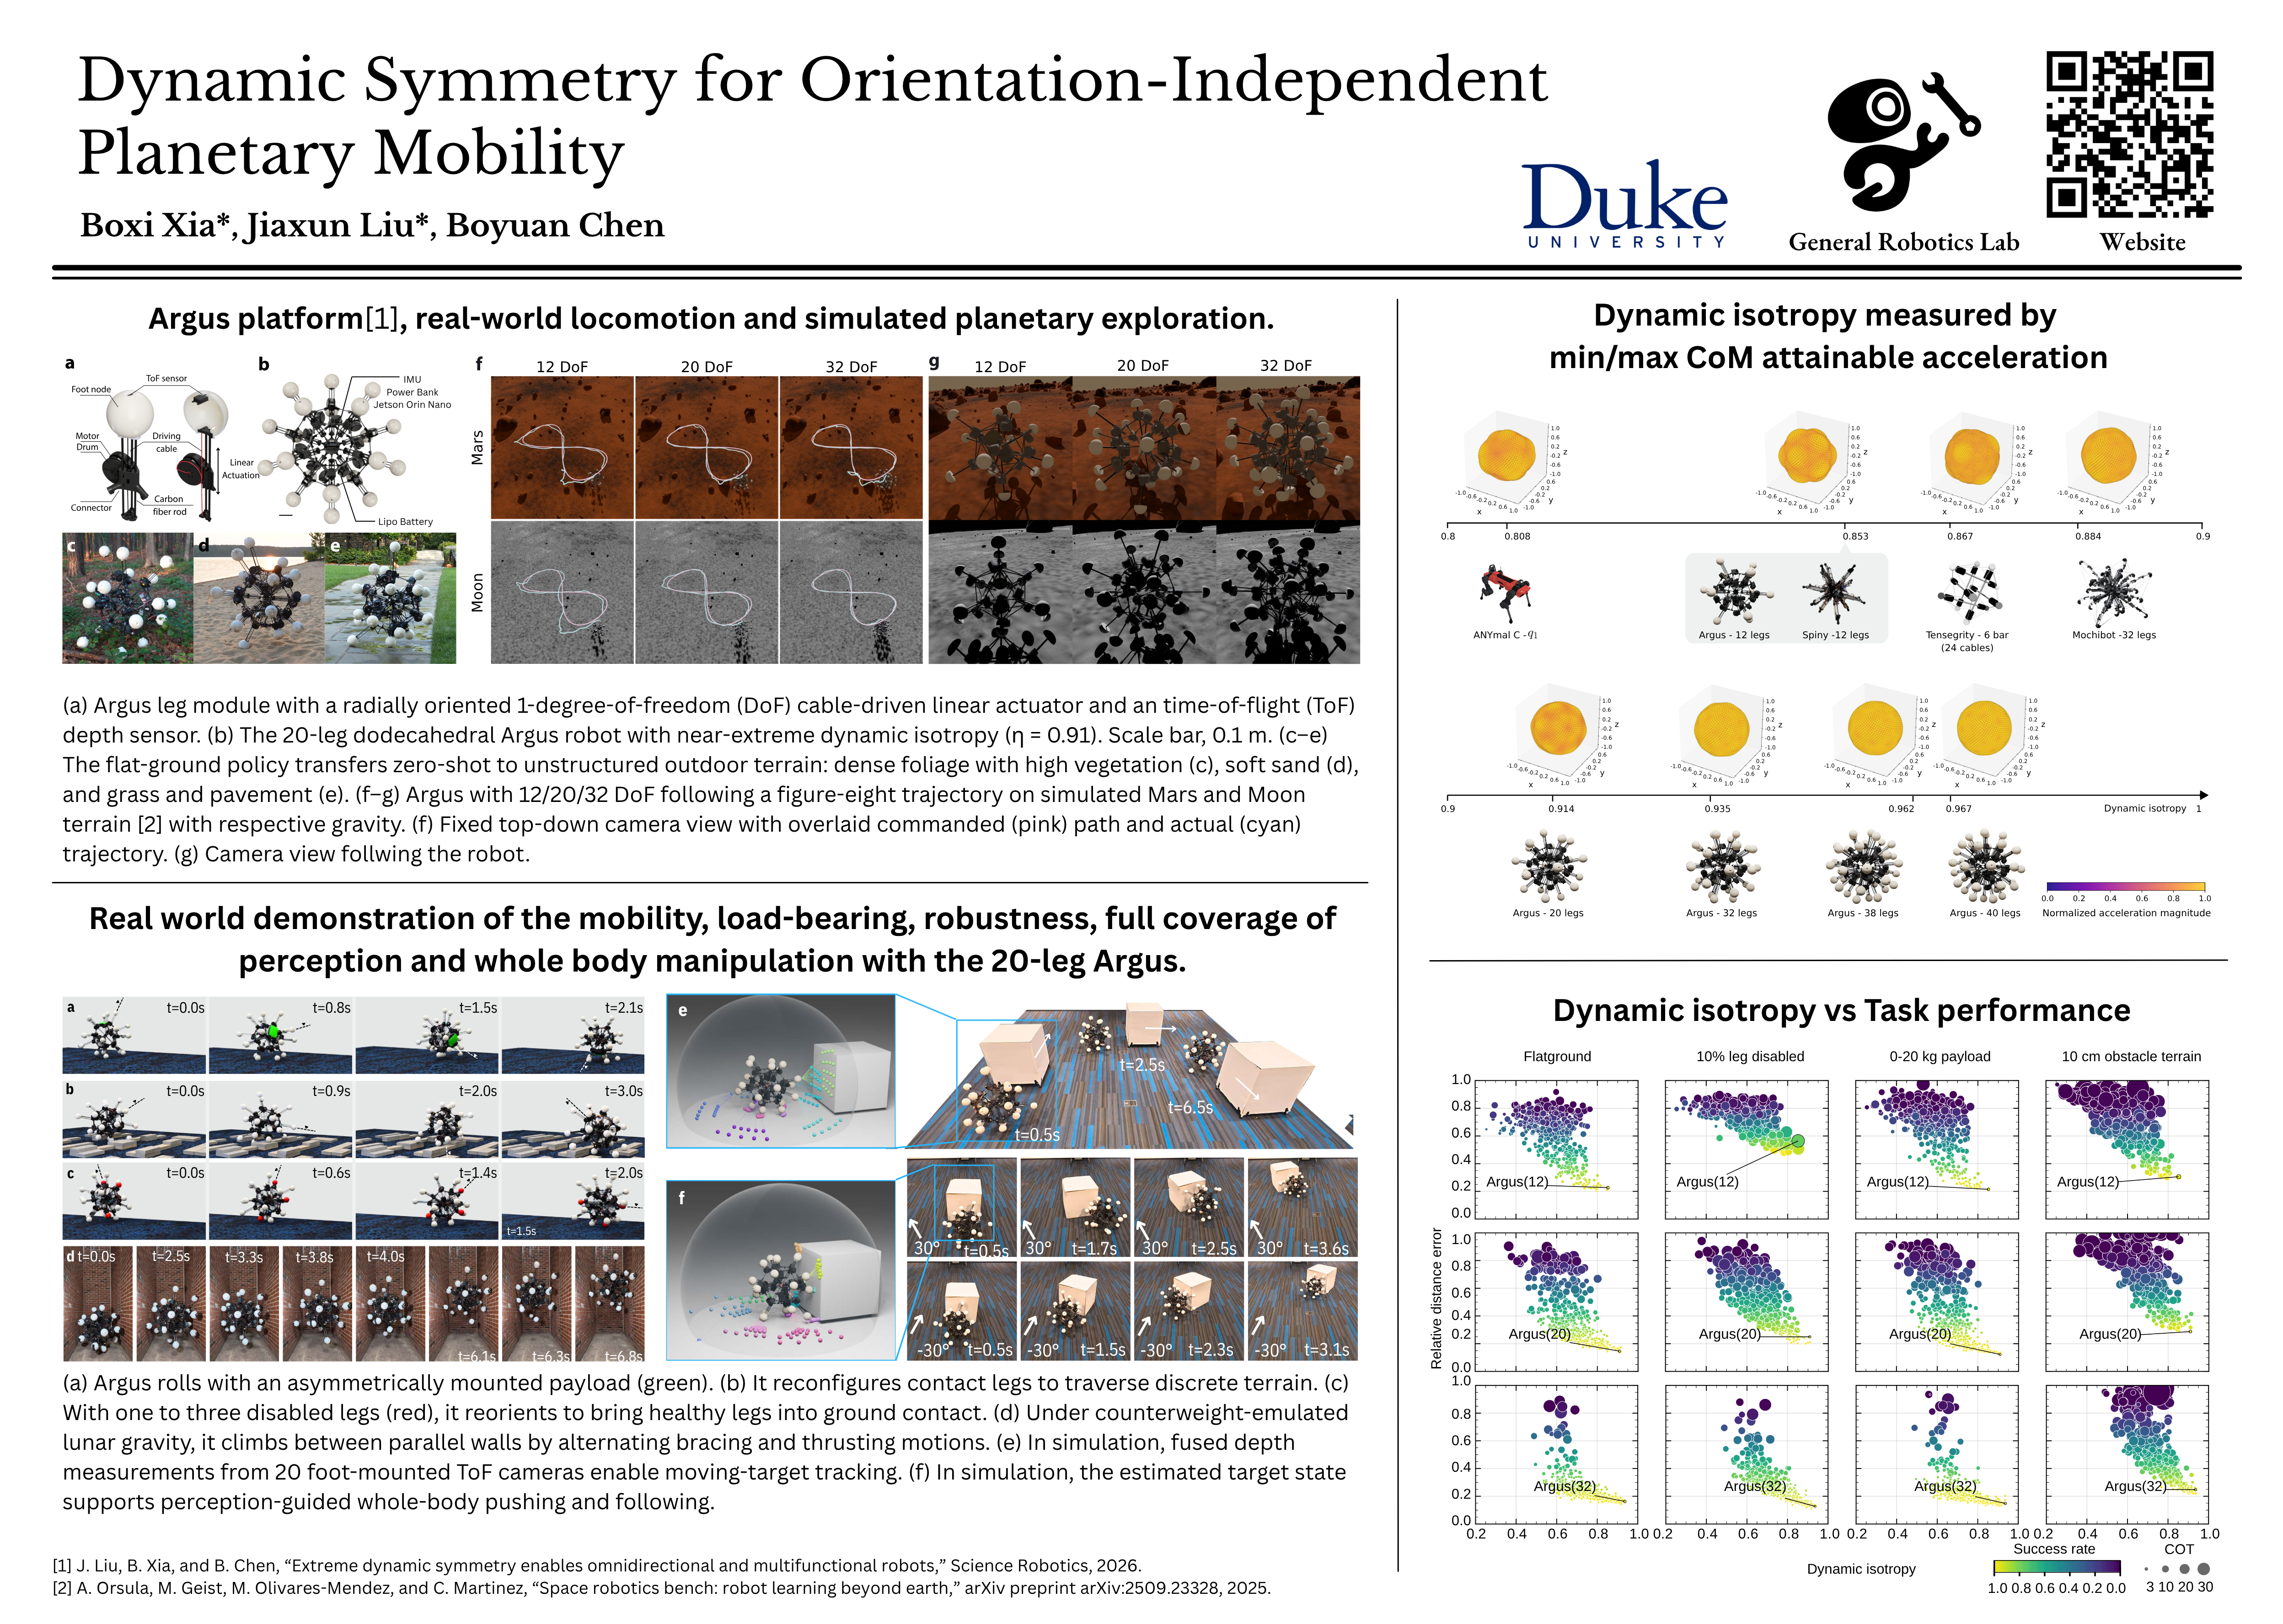
Dynamic Symmetry for Orientation-Independent Planetary Mobility
Jiaxun Liu, Boyuan Chen, Boxi Xia

LLA-MPC on Embedded Hardware: Rapid Adaptive Control with Thousands of Parallel Models
John M Dolan, Maitham AL-Sunni, Henry Z. Liao
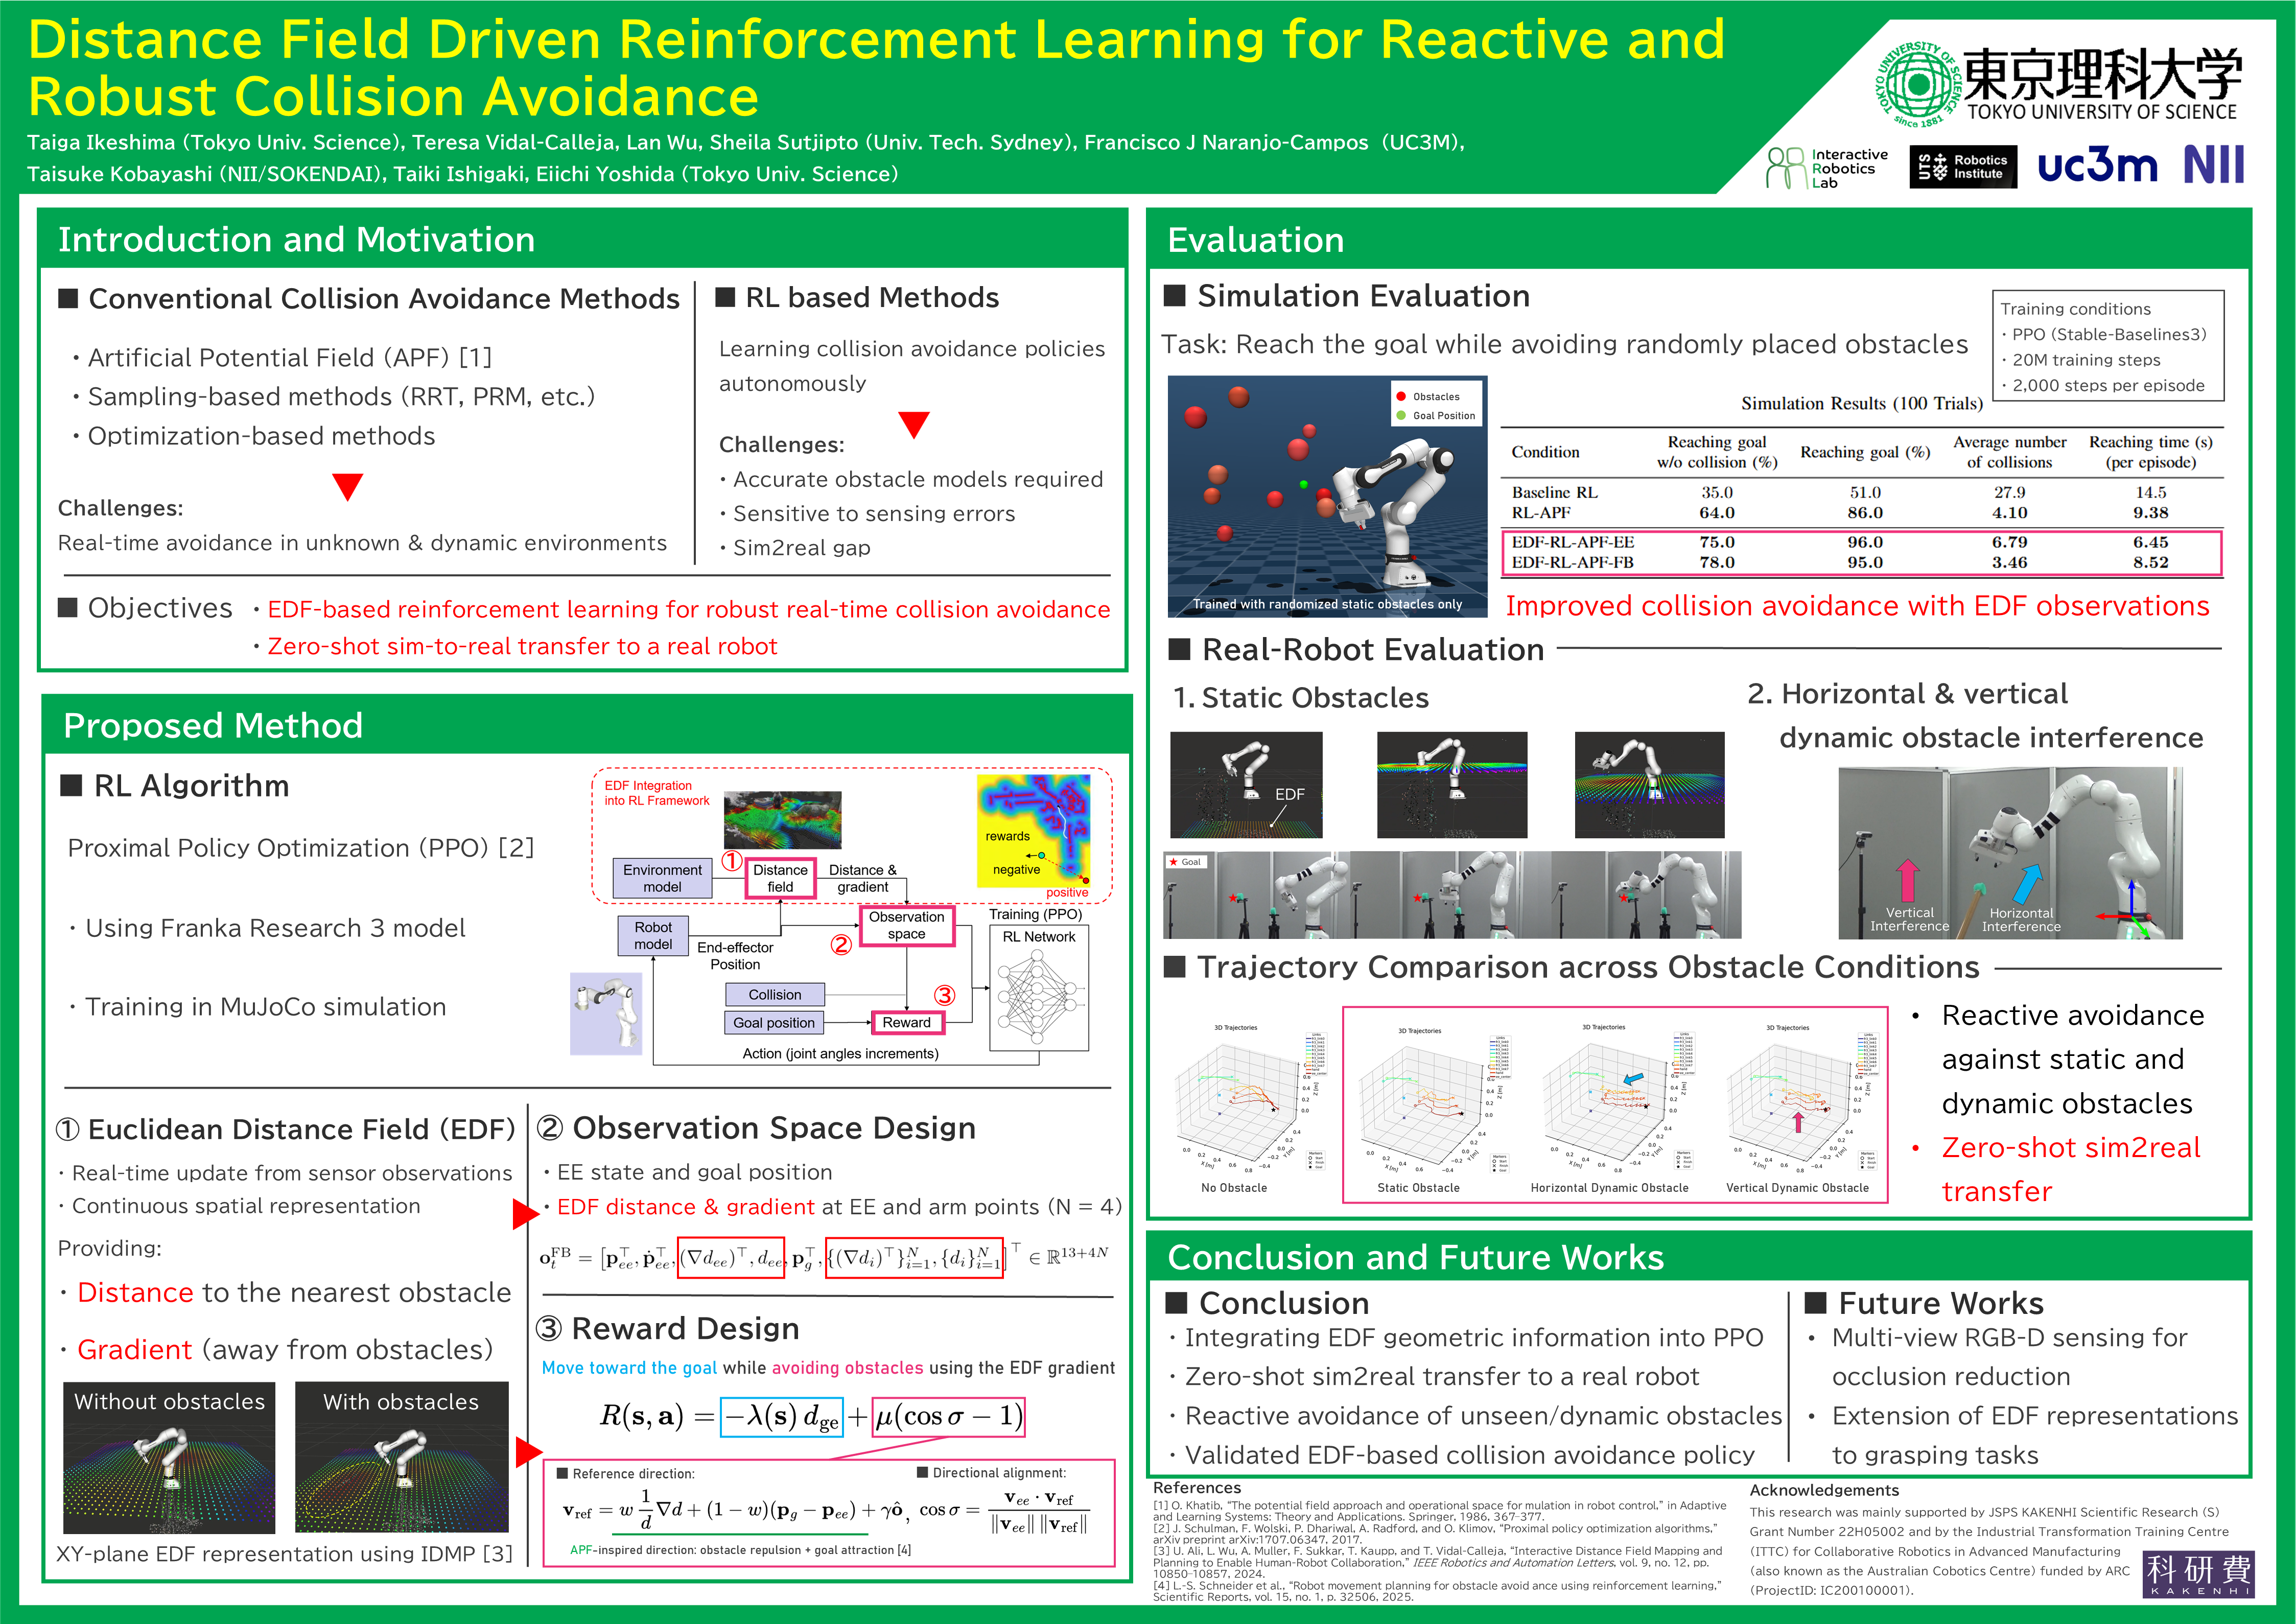
Distance Field Driven Reinforcement Learning for Reactive and Robust Collision Avoidance
Teresa Vidal-Calleja, Taisuke Kobayashi, Taiki Ishigaki, Taiga Ikeshima, Sheila Sutjipto, Lan Wu, Eiichi Yoshida
Bridging the Sim-to-Real Gap for Artificial-Muscle-Driven Continuum Robots Using Physics-Informed Koopman-MPC
Yi Ren, Jiefeng Sun, Jiahe Wang, Eron Ristich, Eric Weissman
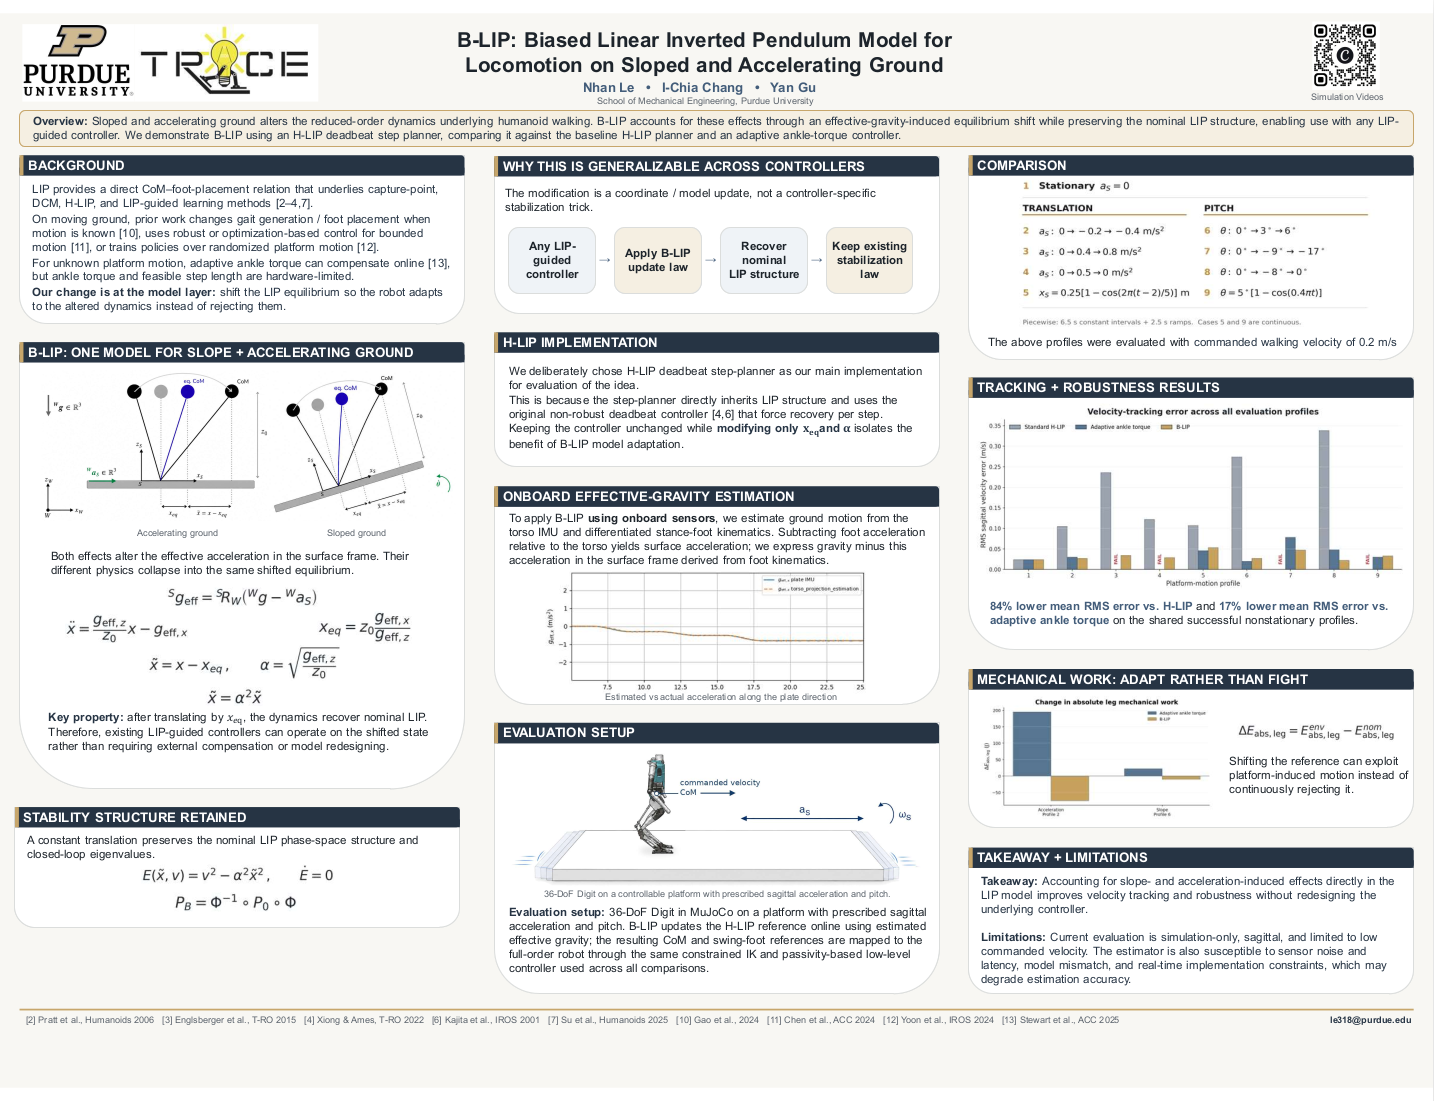
B-LIP: Biased Linear Inverted Pendulum Model for Locomotion on Sloped and Accelerating Ground
Yan Gu, Nhan Le, I-Chia Chang
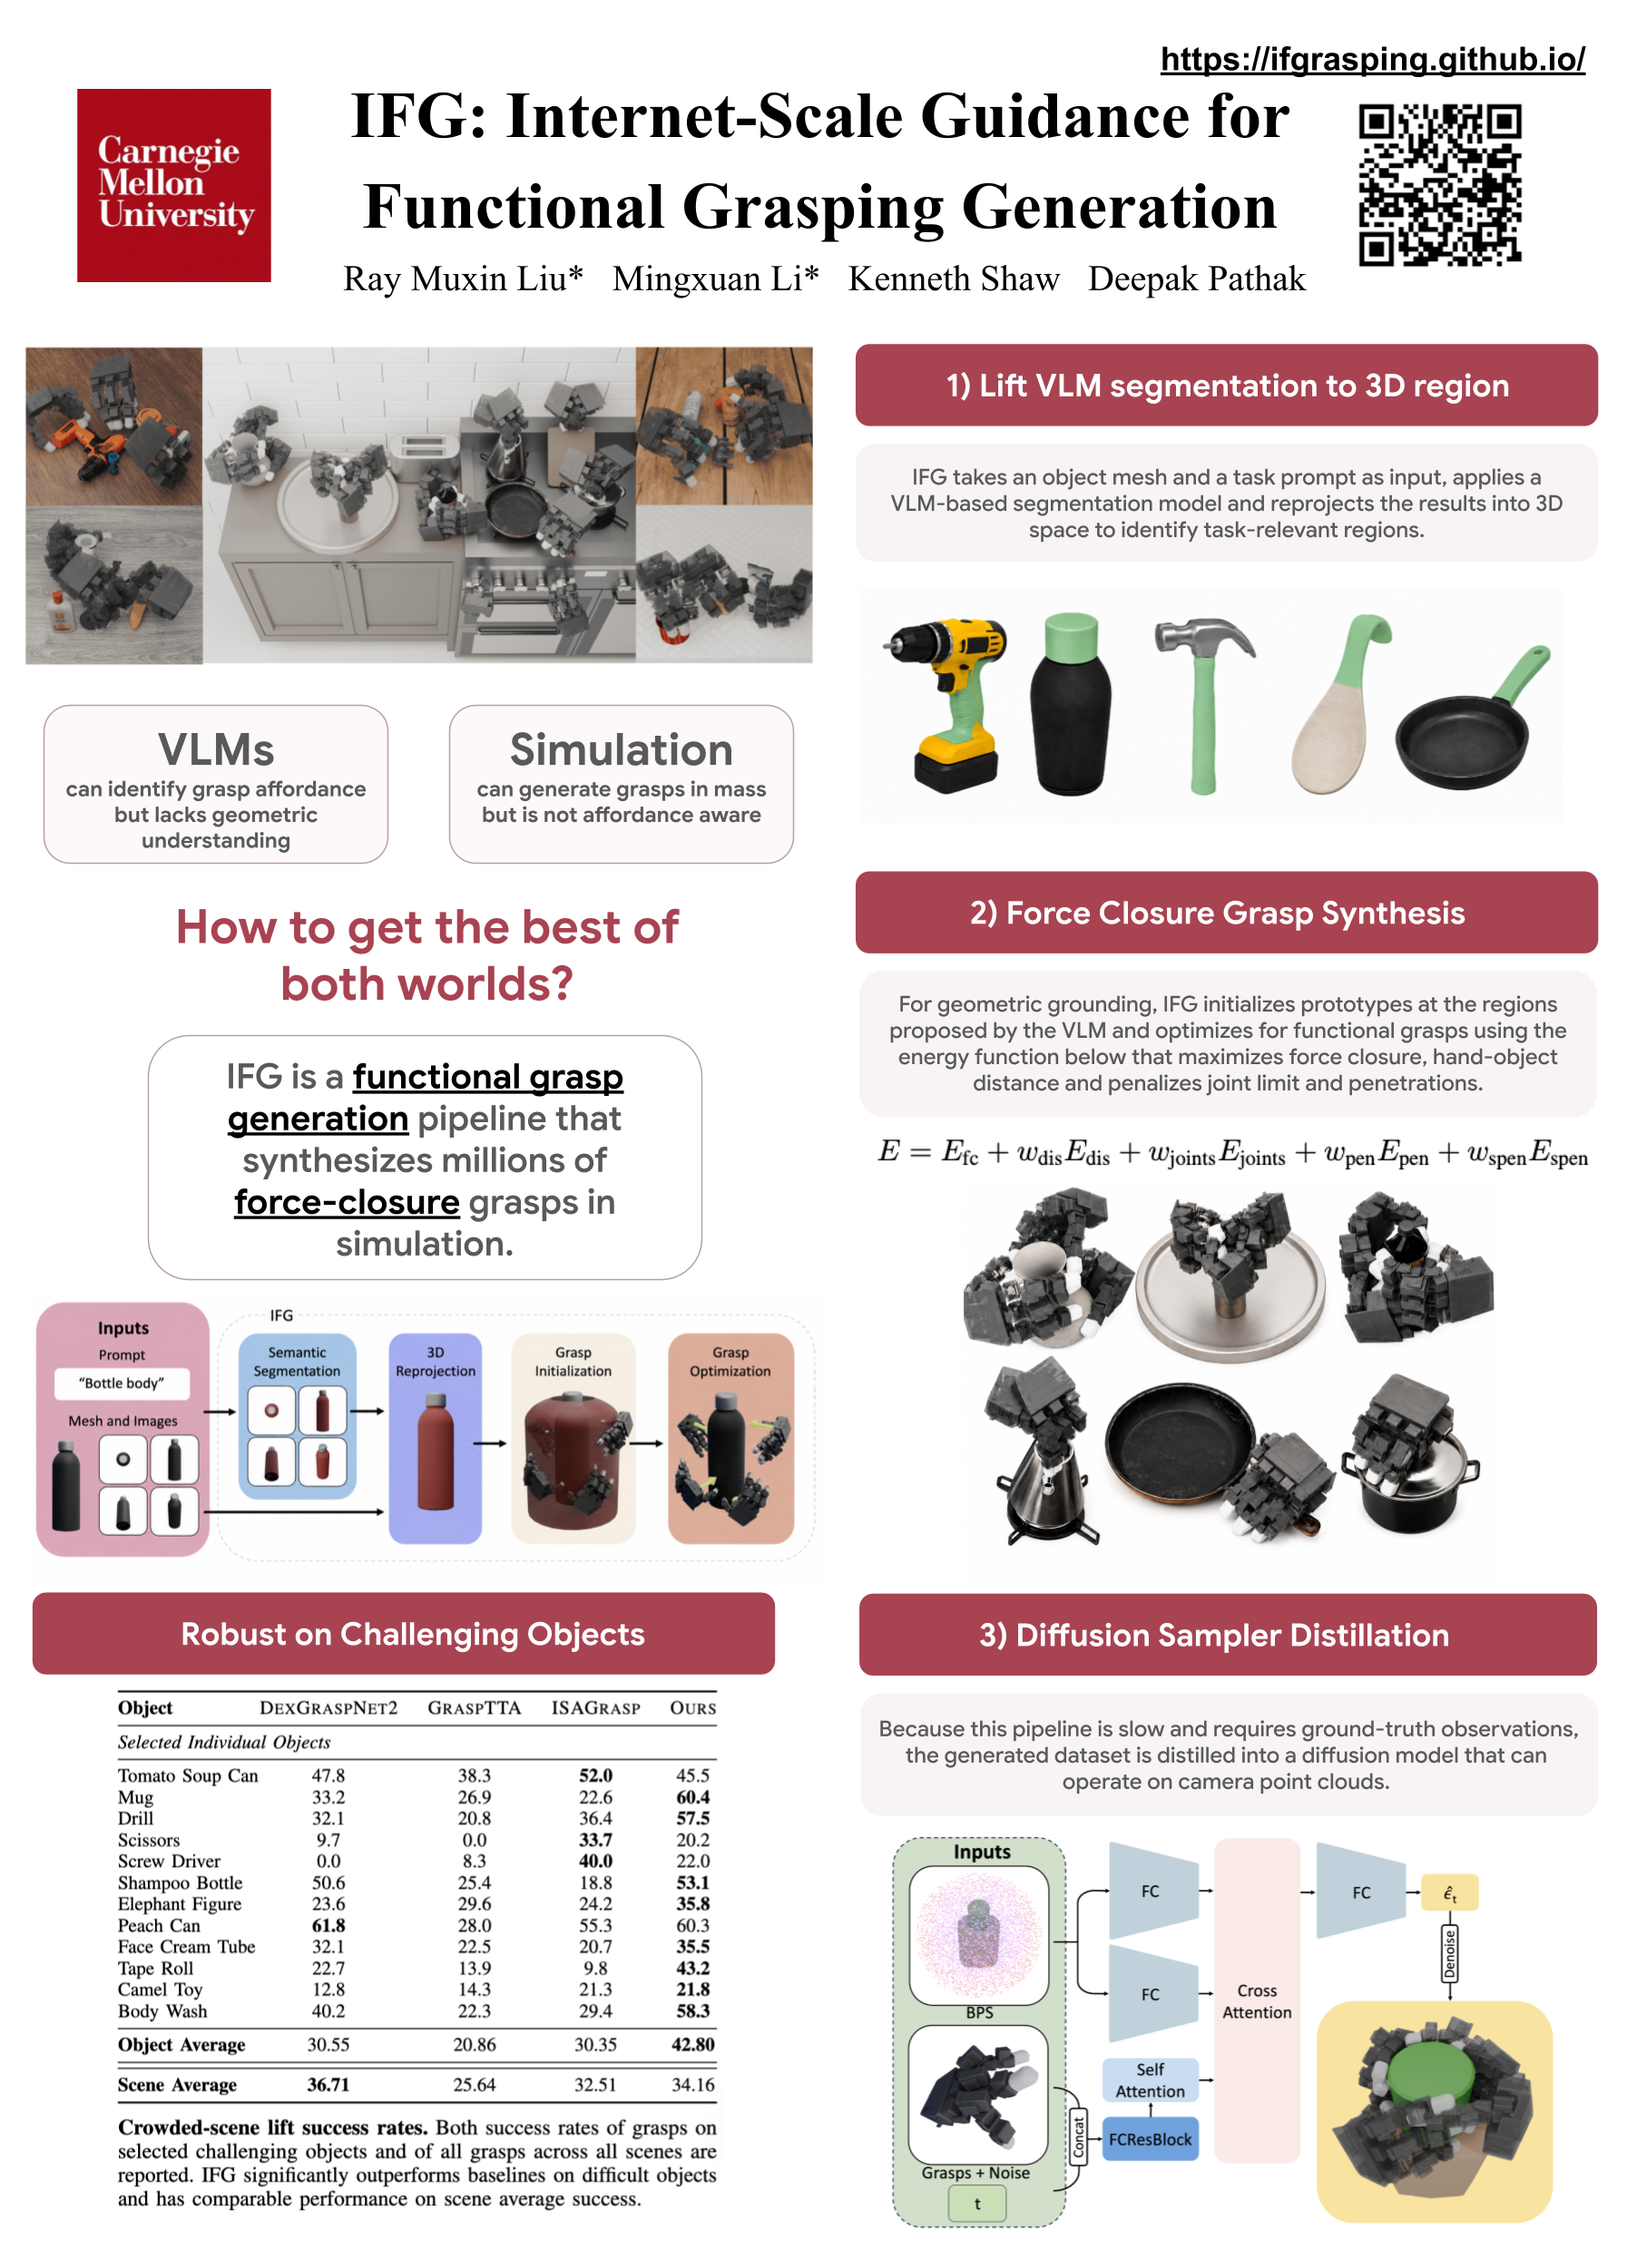
IFG: Internet-Scale Guidance for Functional Grasping Generation
Muxin Liu, Mingxuan Li, Kenneth Shaw, Deepak Pathak
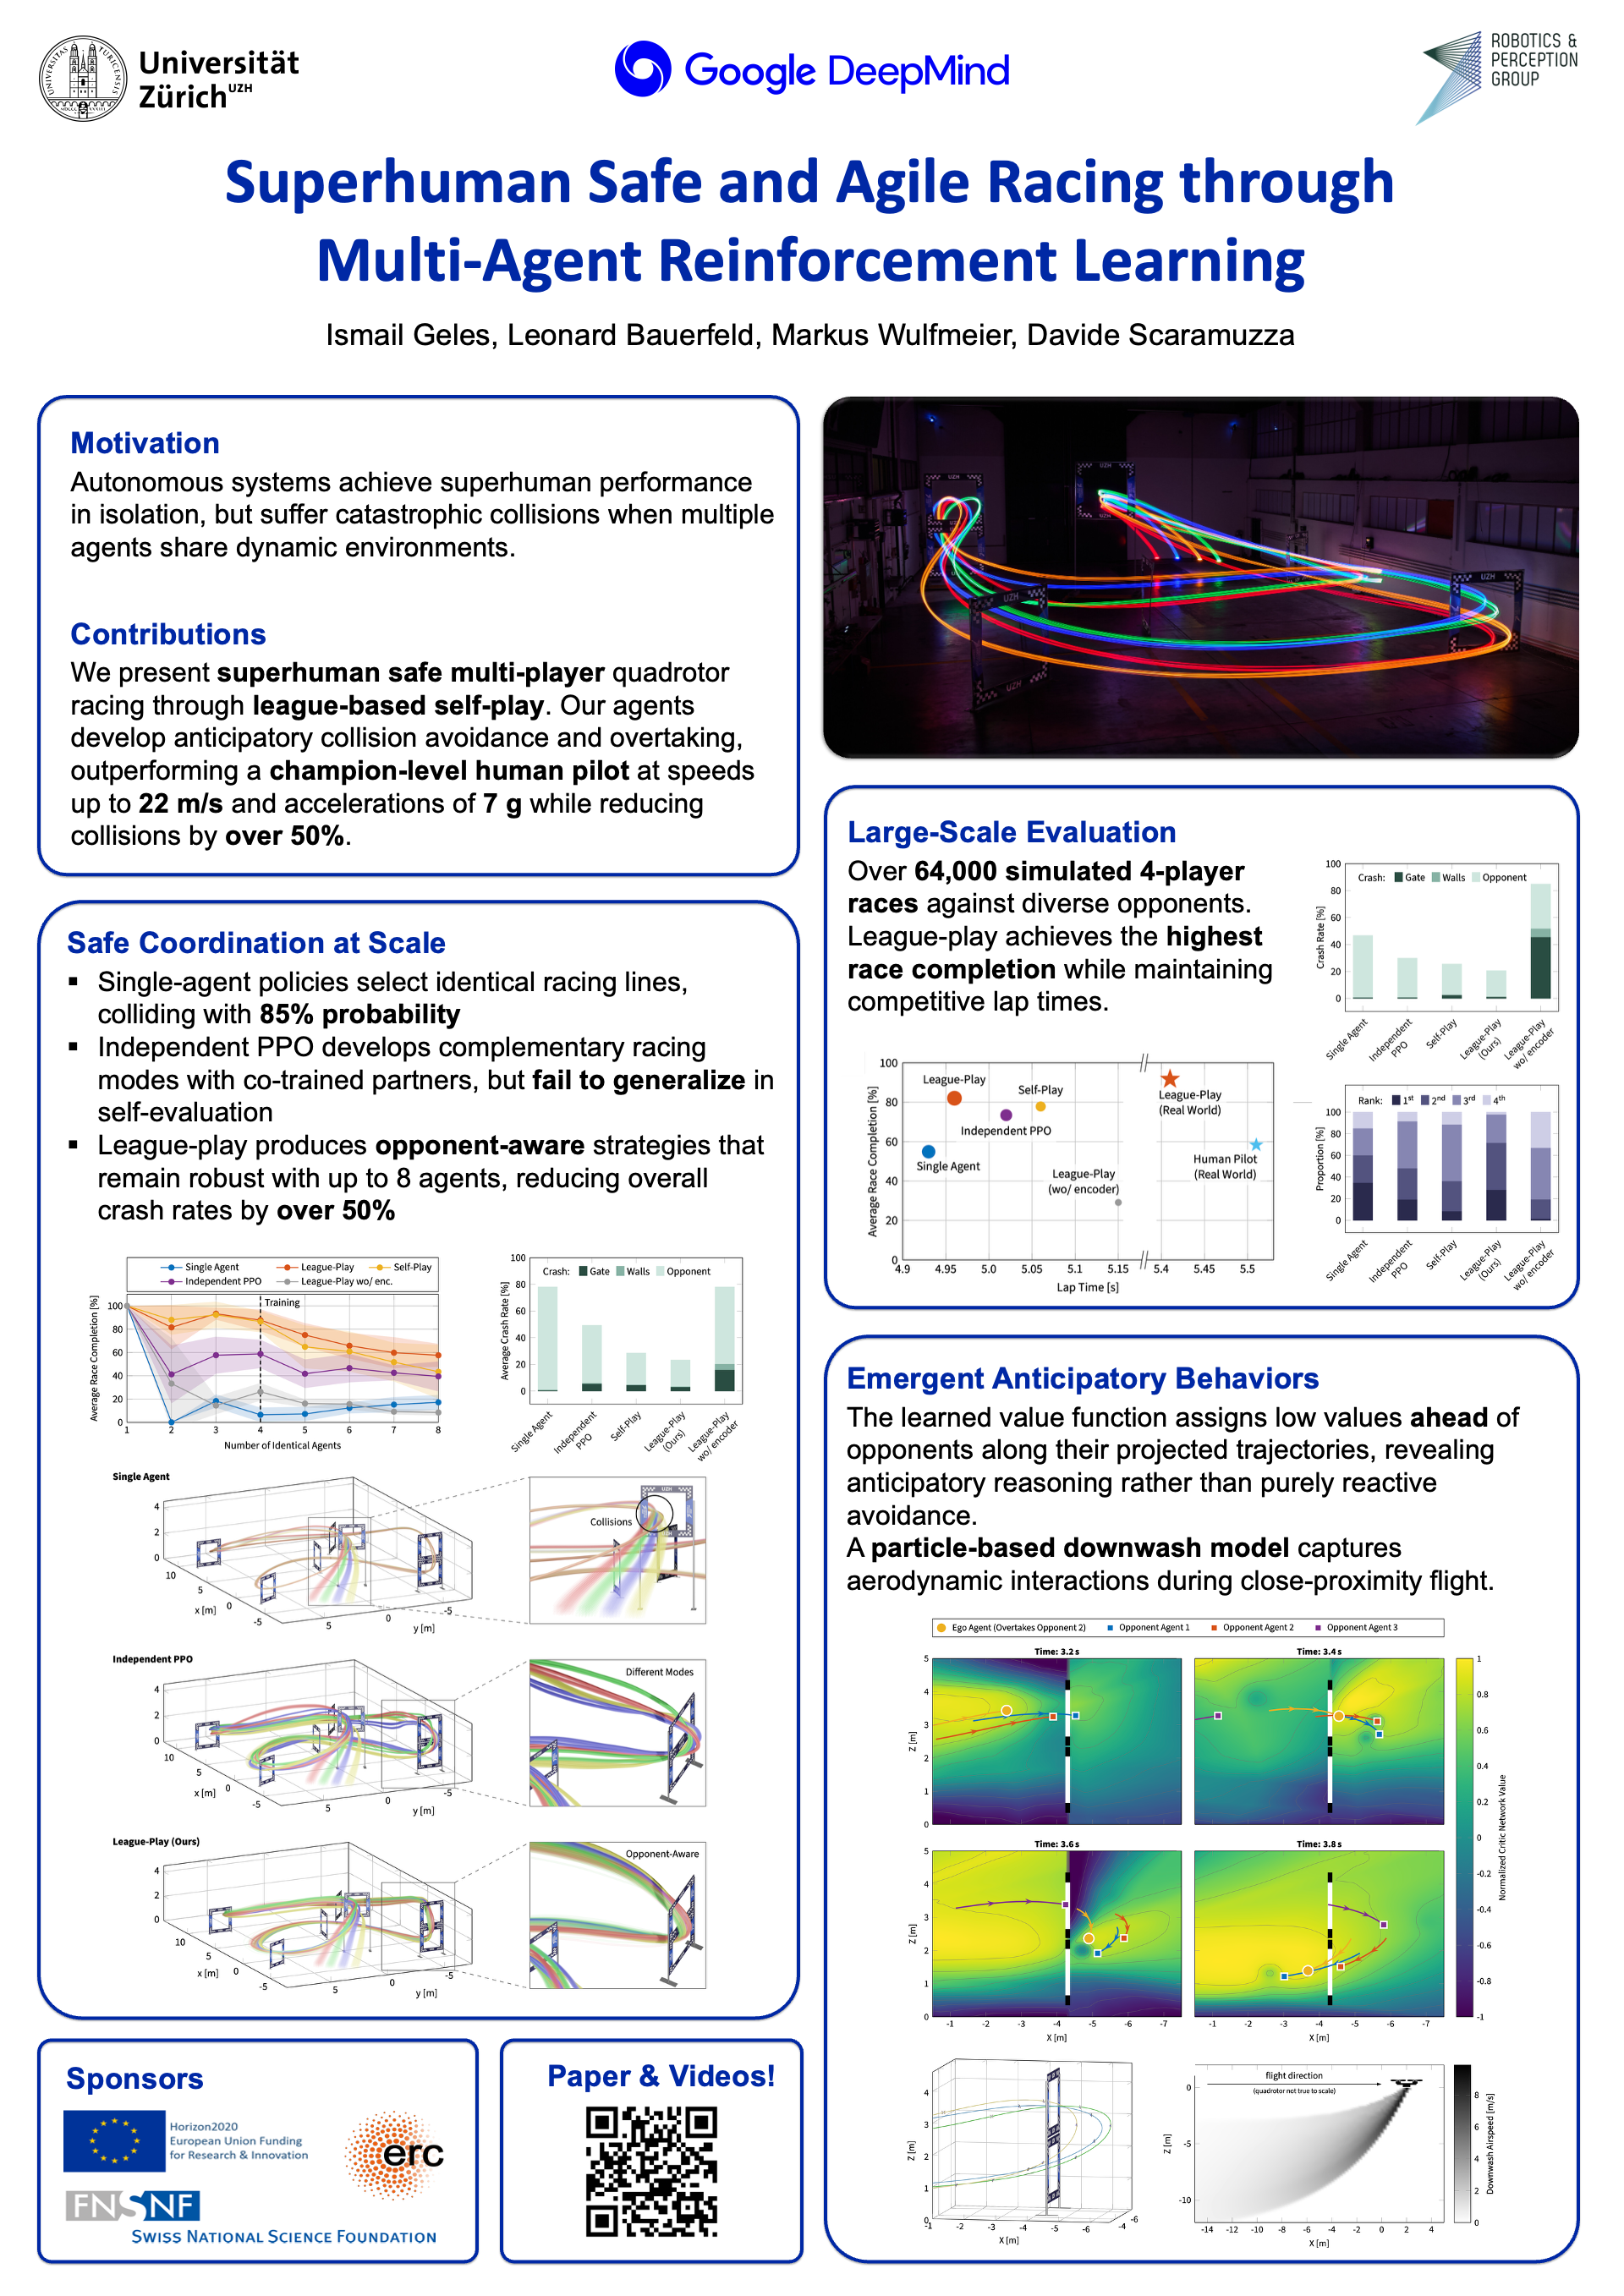
Superhuman Safe and Agile Racing through Multi-Agent Reinforcement Learning
Markus Wulfmeier, Leonard Bauersfeld, Ismail Geles, Davide Scaramuzza

Adaptive Rejection of Unknown Hybrid Sinusoidal Disturbances for Bipedal Walking on Multi-Directional Moving Platforms
Yan Gu, Petros Ioannou, I-Chia Chang
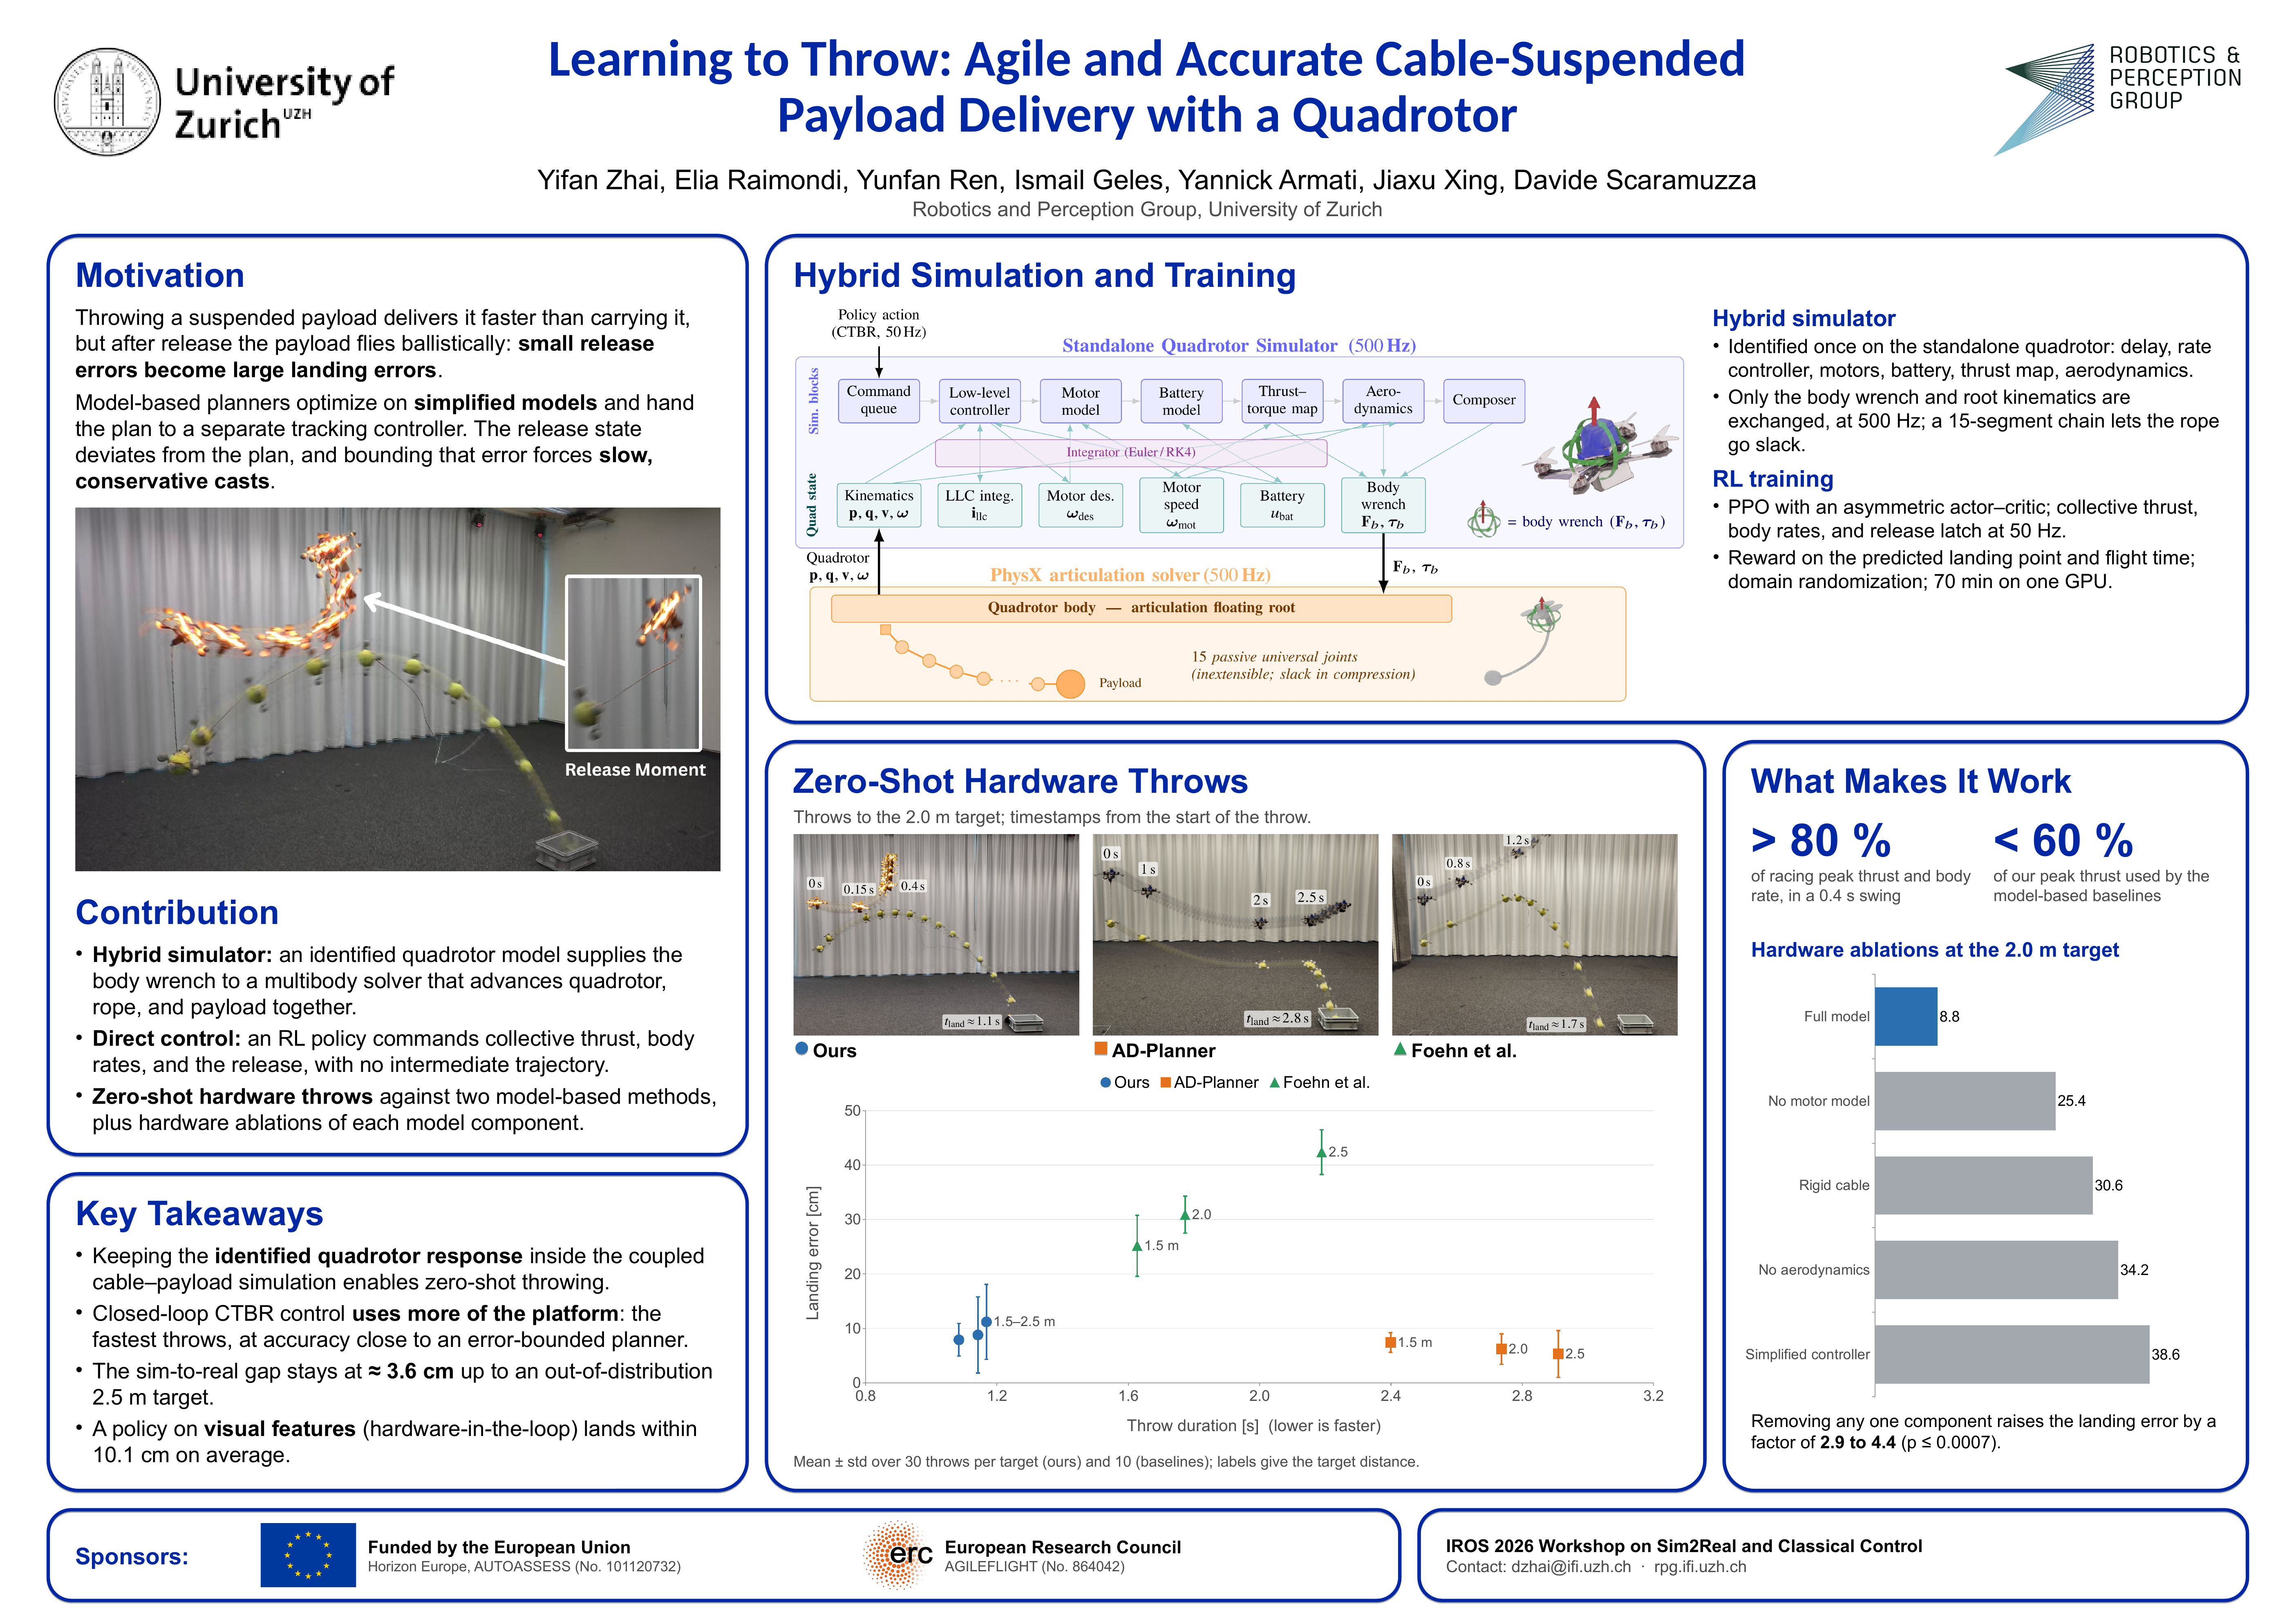
Learning to Throw: Agile and Accurate Cable-Suspended Payload Delivery with a Quadrotor
Yunfan Ren, Yifan Zhai, Jiaxu Xing, Ismail Geles, Davide Scaramuzza
Drone Soccer: Learning to Manipulate with Multicopter Downwash
Yutong Wang, Varun Kandiyappan, Sebastian Scherer, Neelay Joglekar, Junyi Geng, Bavin Saravanan
Perching on a Powerline That Moves: Simulator Fidelity for a Wind-Coupled Oscillating Target
Steven Willits, Shreya Sreekantham, Sebastian Scherer, John Liu, Andrew Sippel
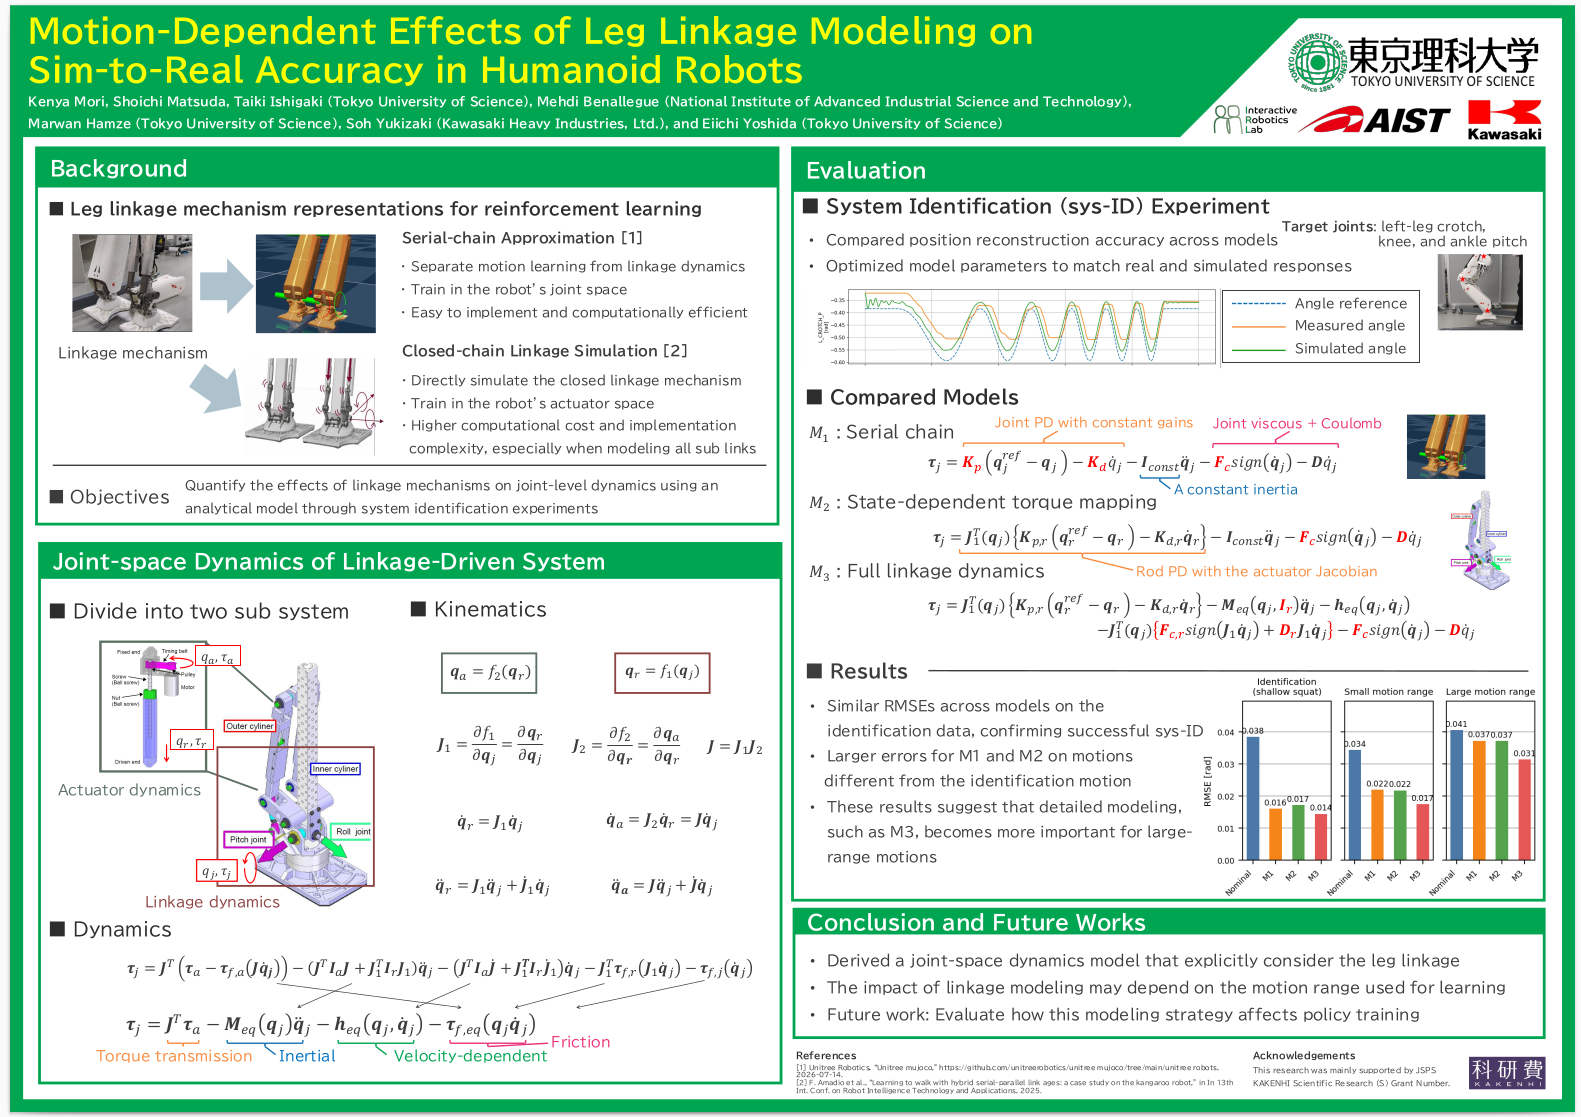
Motion-Dependent Effects of Leg Linkage Modeling on Sim-to-Real Accuracy in Humanoid Robots
Yukizaki Soh, Taiki Ishigaki, Shoichi Matsuda, Mehdi Benallegue, Marwan Hamze, Kenya Mori, Eiichi Yoshida
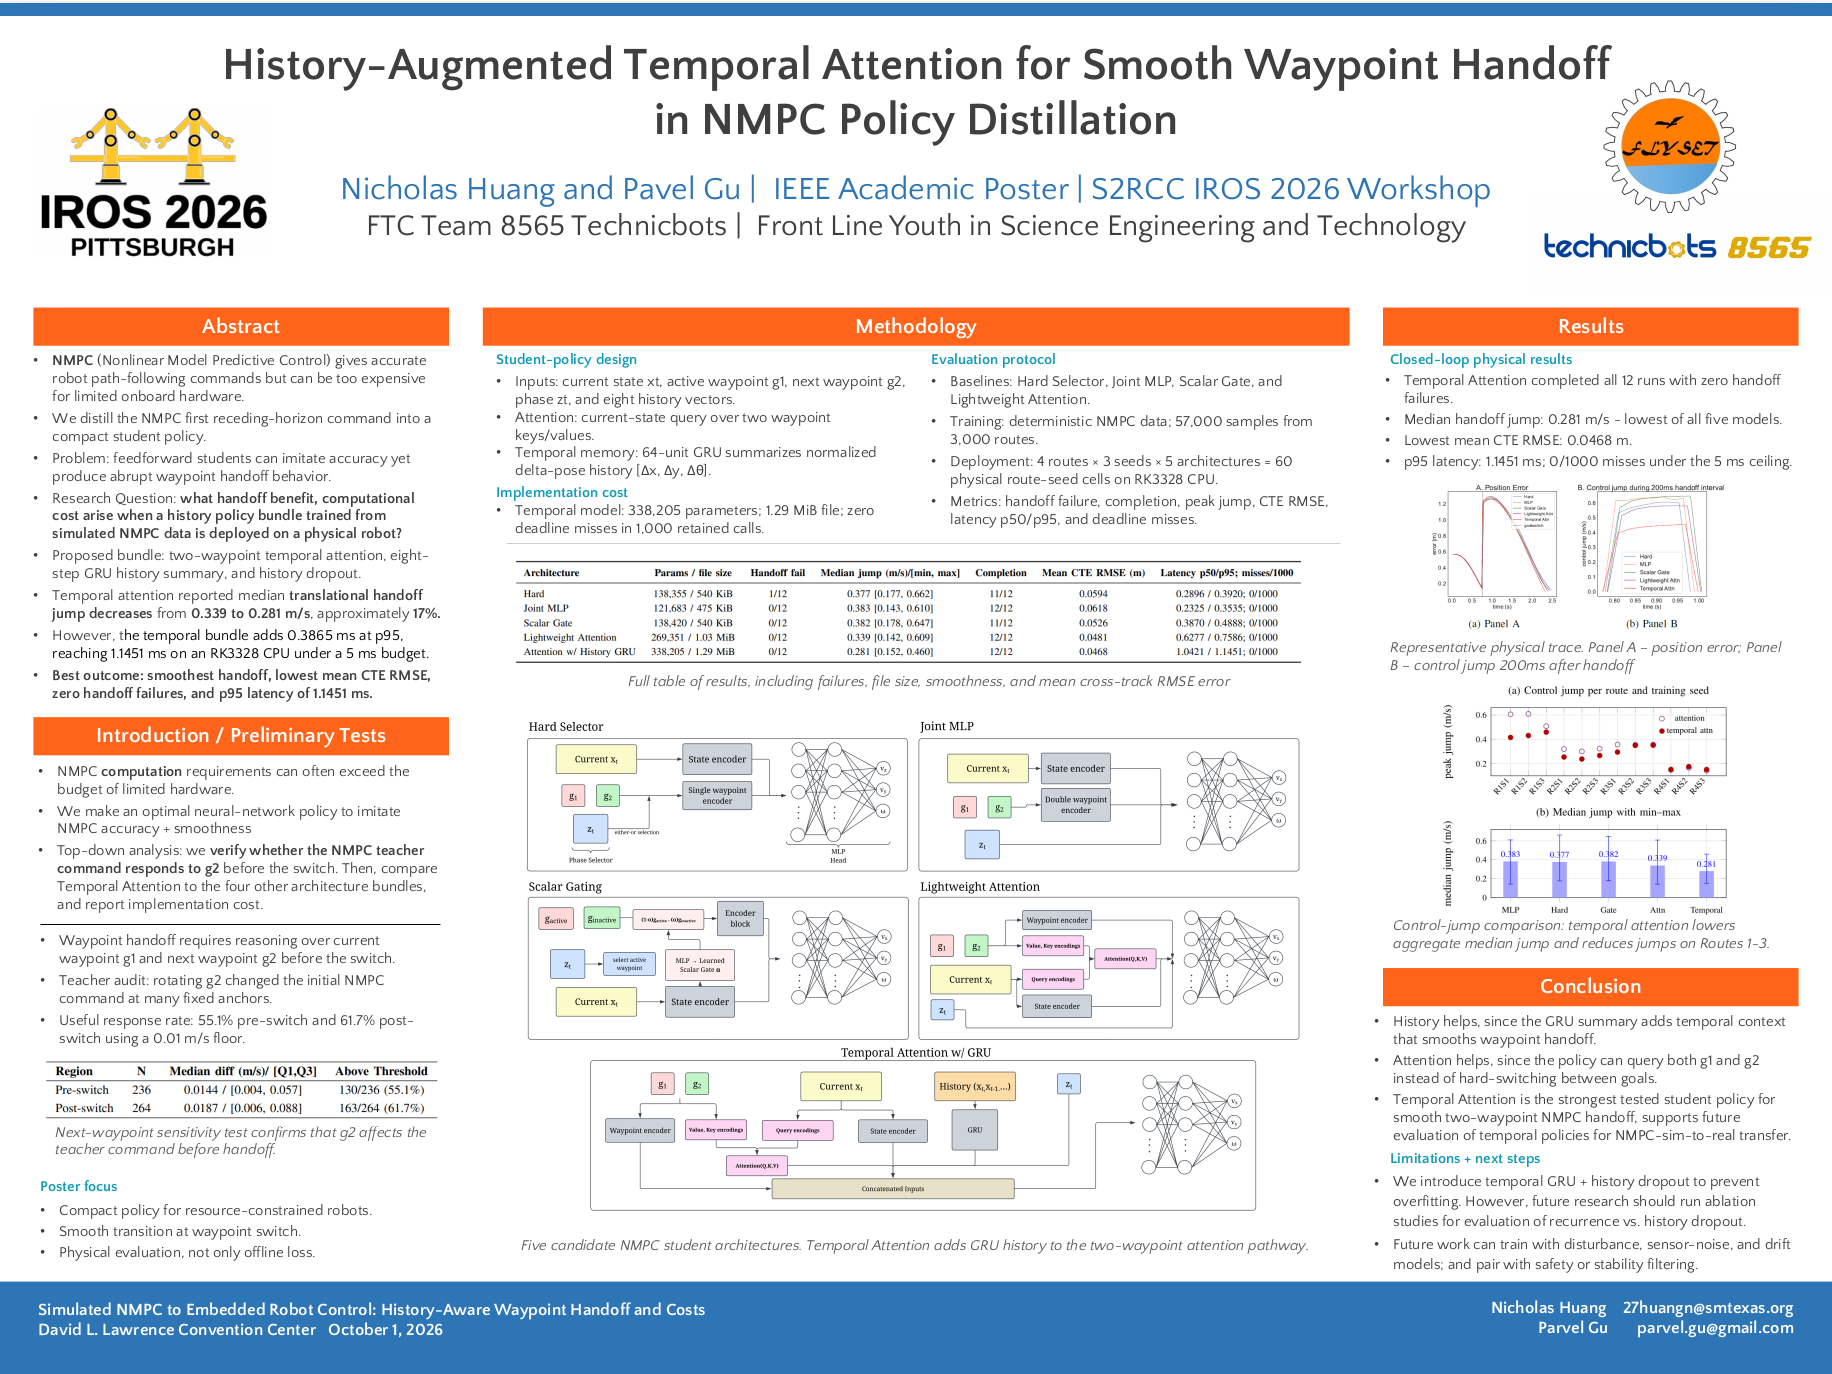
Simulated NMPC to Embedded Robot Control: History-Aware Waypoint Handoff and Costs
Parvel Gu, Nicholas Huang
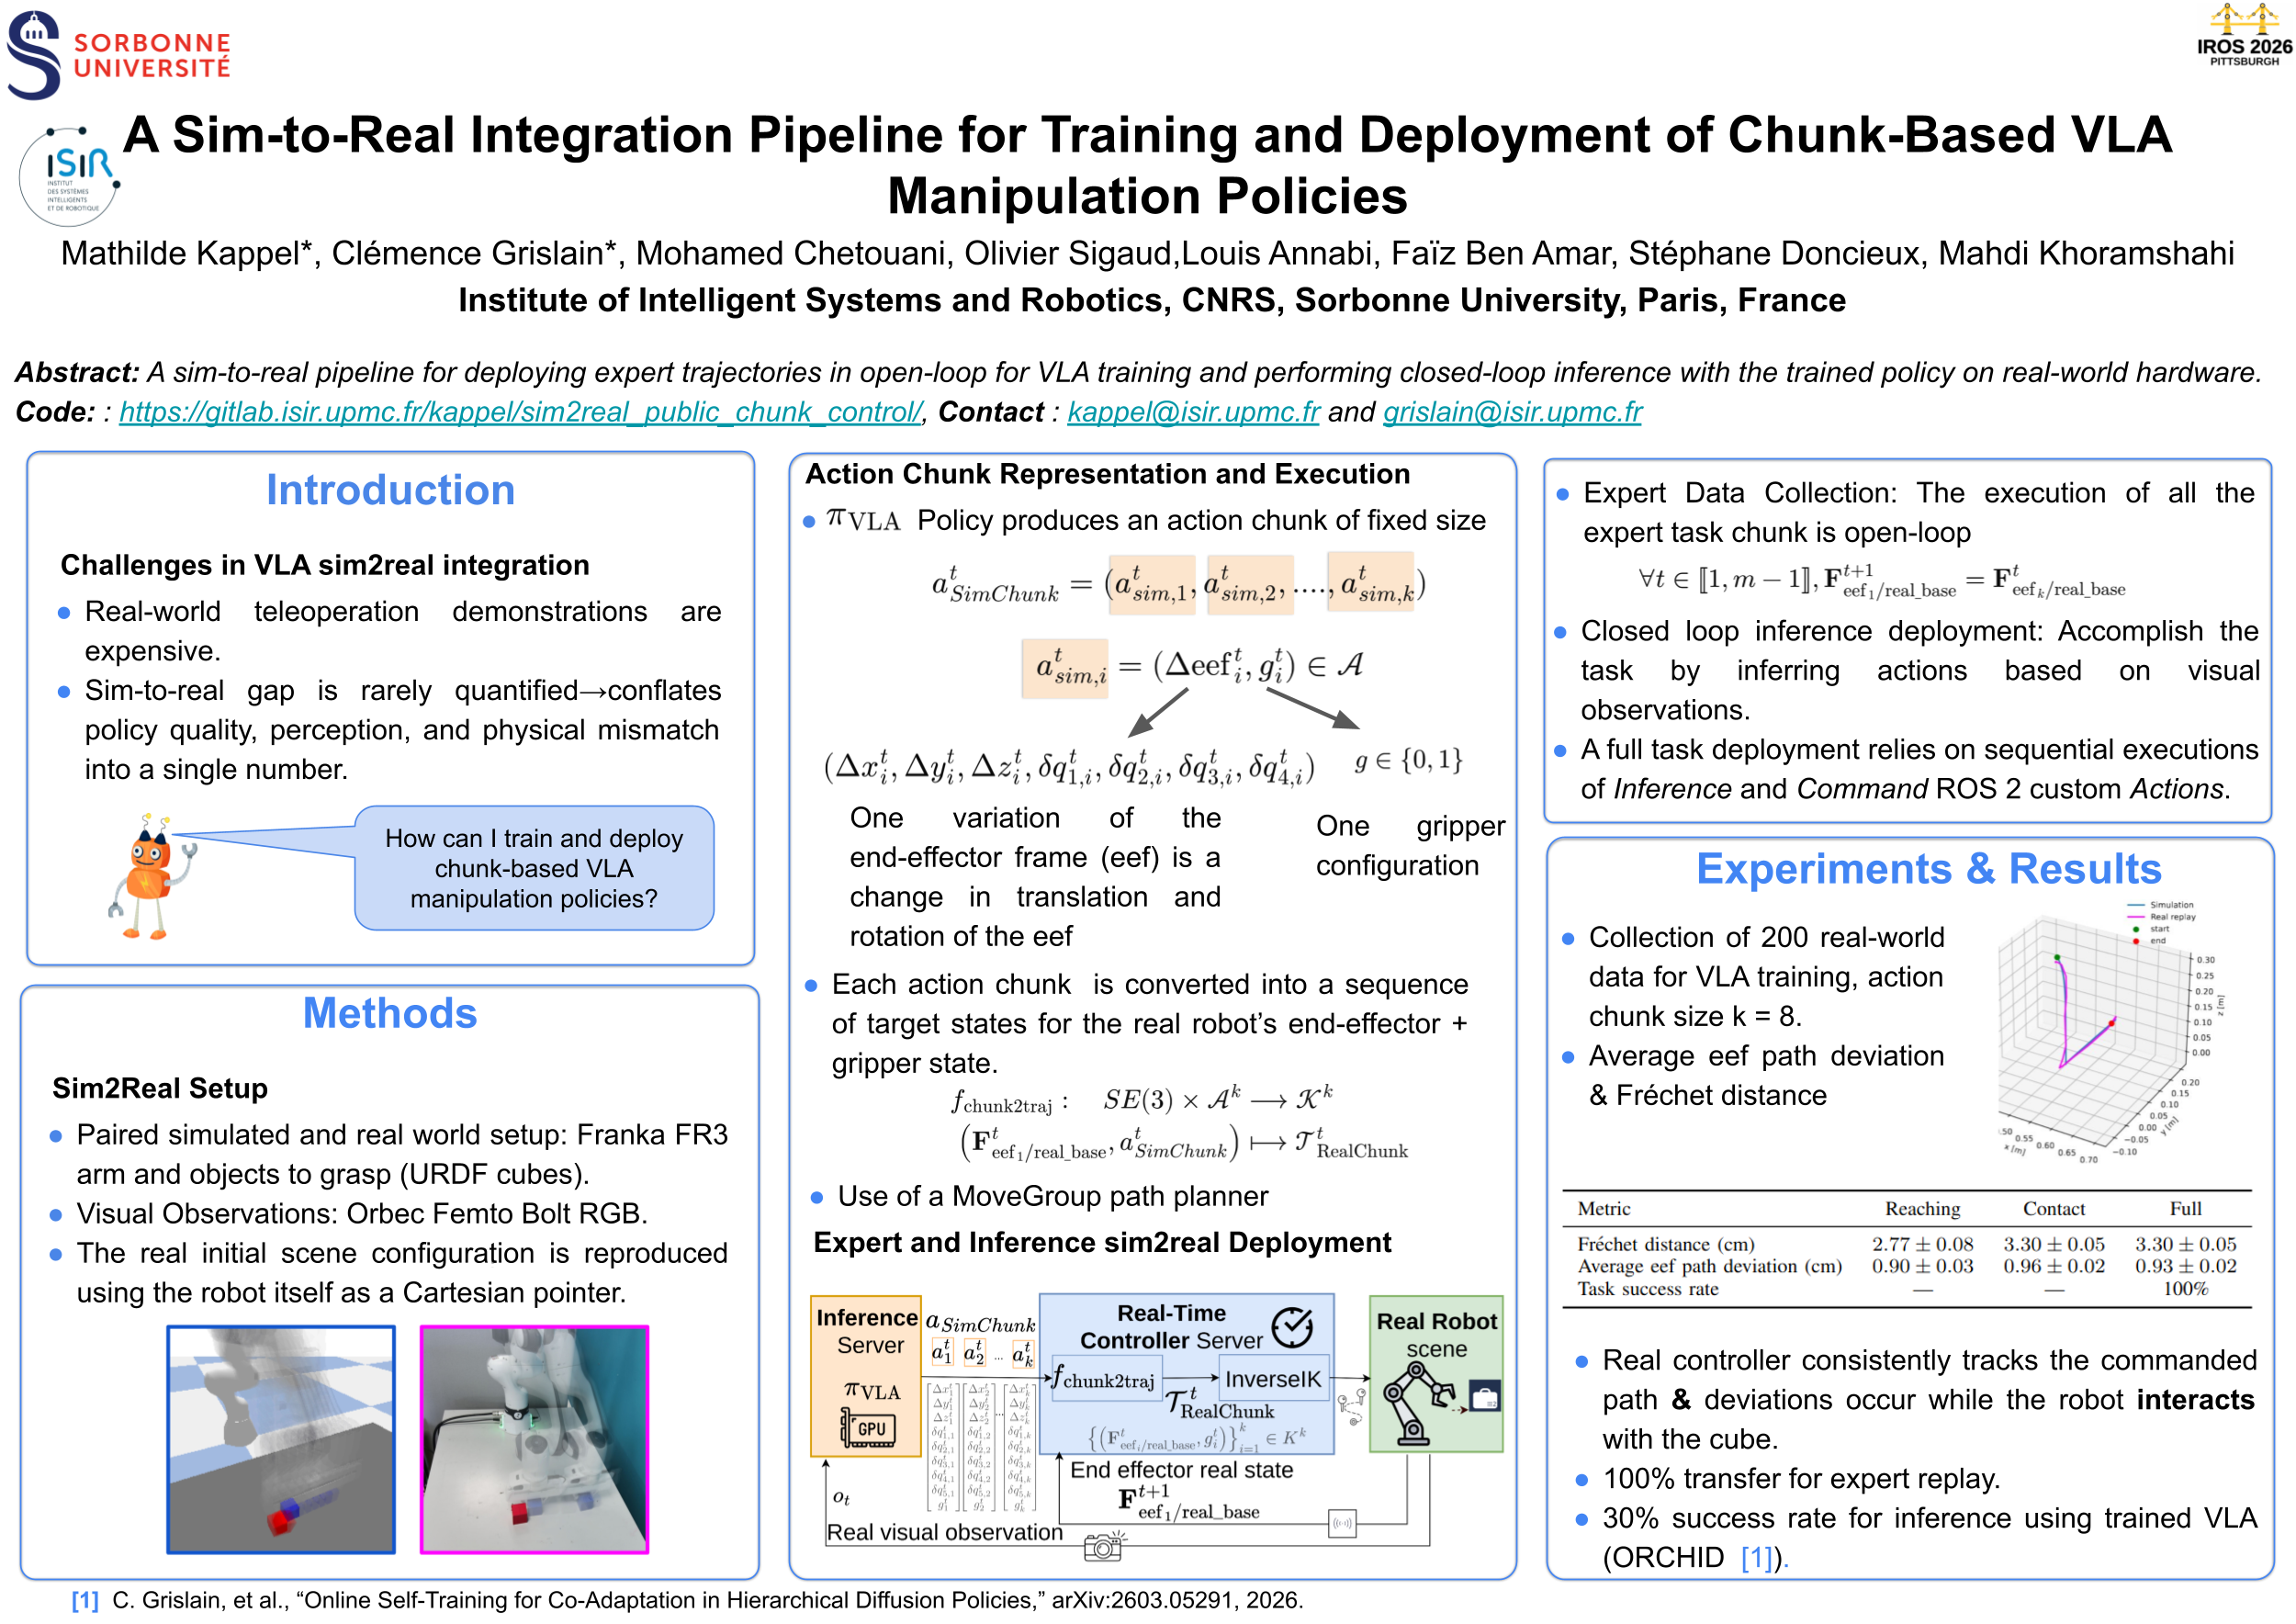
A Sim-to-Real Integration Pipeline for Training and Deployment of Chunk-Based VLA Manipulation Policies
Stephane Doncieux, Olivier Sigaud, Mohamed CHETOUANI, Mathilde Kappel, Mahdi Khoramshahi, Louis Annabi, Faiz BEN AMAR, Clémence Grislain
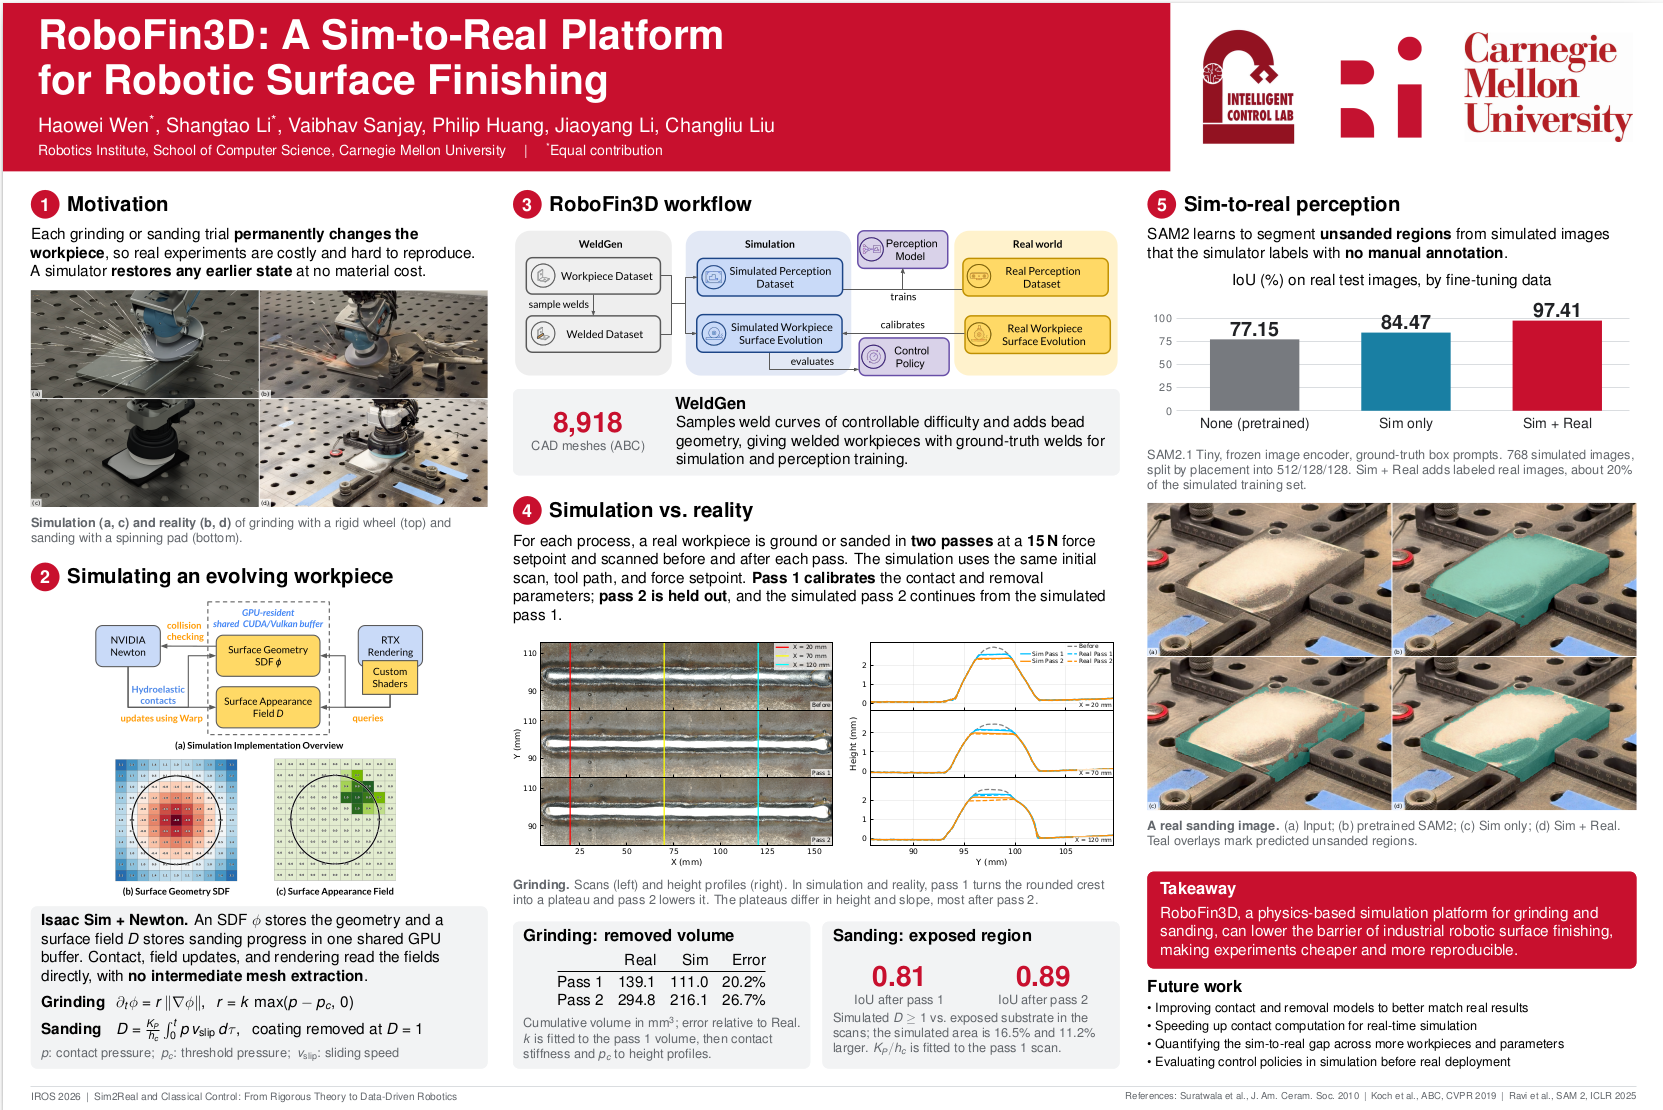
RoboFin3D: A Sim-to-Real Platform for Robotic Surface Finishing
Philip Huang, Vaibhav Sanjay, Shangtao Li, Jiaoyang Li, Haowei Wen, Changliu Liu